DS-PICK
High-Mix Picking Automation with a Multi-Finger Robotic Gripper

Multi-Object Picking Automation Solution with an Articulated Robotic Gripper
DS-PICK is a robotic picking automation solution designed to handle objects of various shapes and sizes with a single gripper.
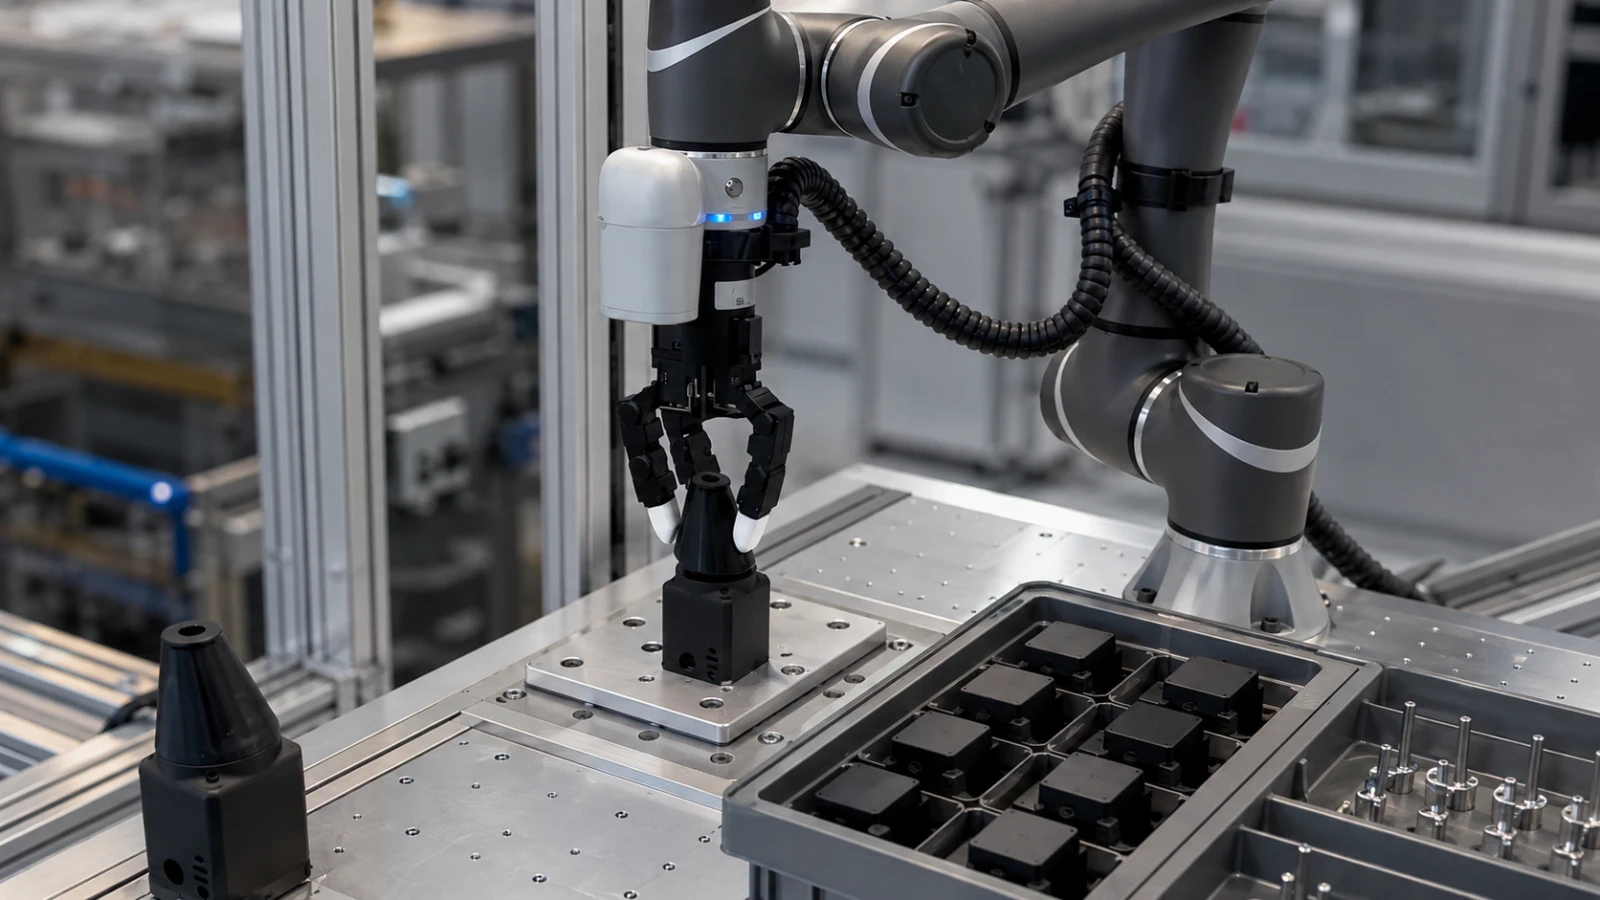
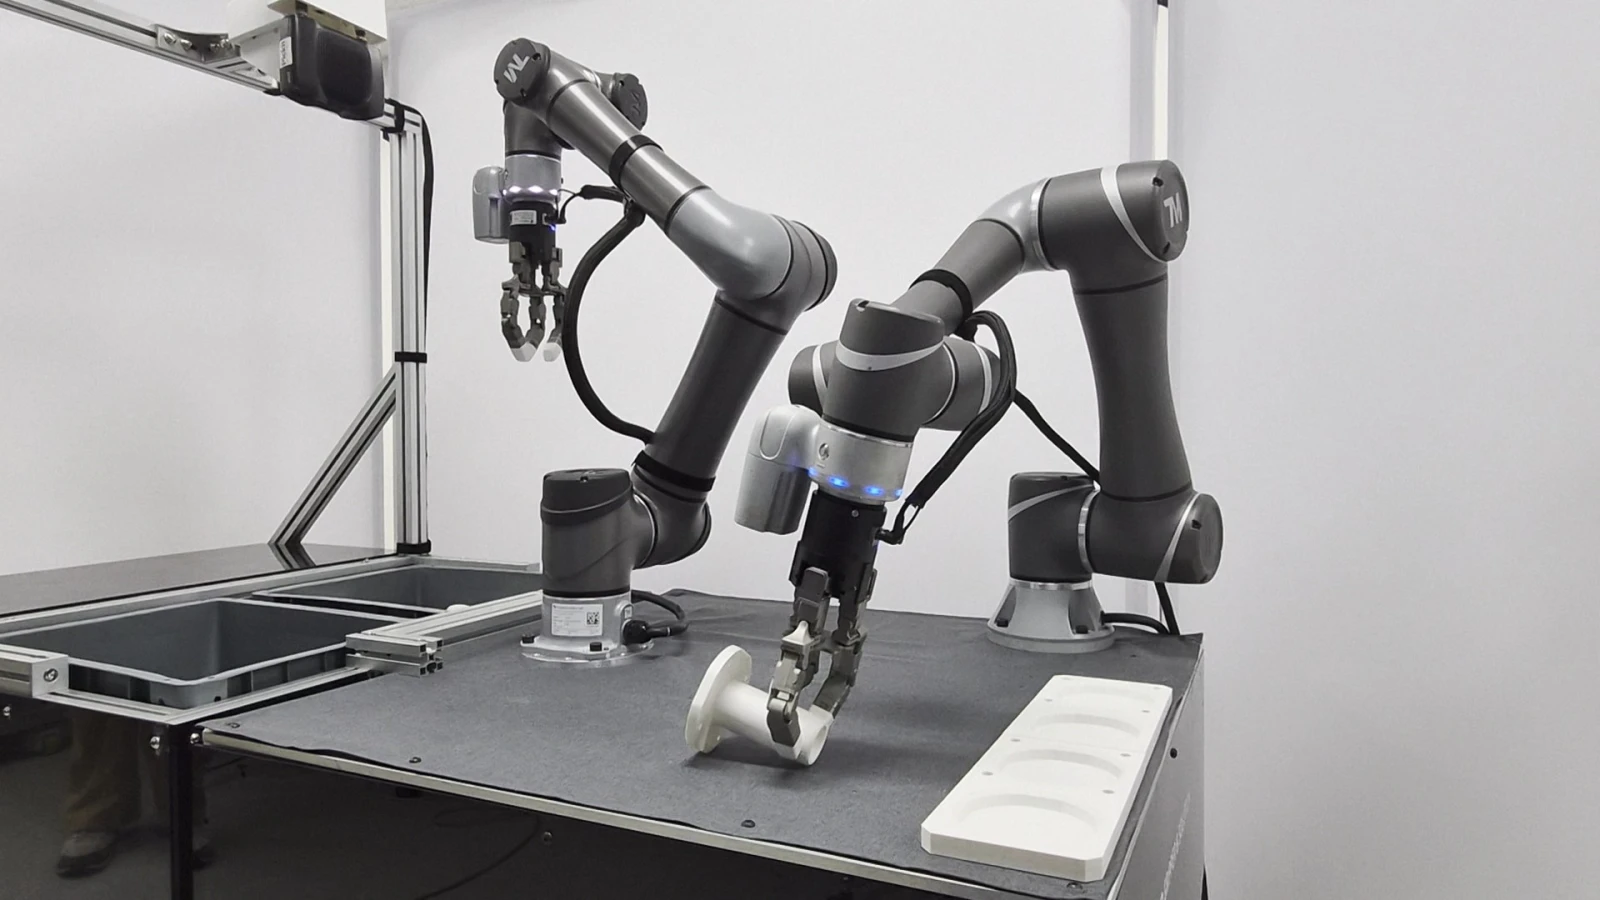
By integrating TESOLLO’s articulated robotic gripper DG-3F-M with a robot arm, 3D vision system, and picking software, DS-PICK detects the position and orientation of objects and applies an appropriate grasping strategy based on object characteristics to automate picking, transfer, and sorting operations.
Its ability to handle objects of various shapes with a single gripper enables a wide range of applications, from multi-part handling in automotive, electronics, and general manufacturing to Piece Picking in logistics and e-commerce.
Handling a Wide Variety of Objects
In automation environments, as the number of products or components increases, dedicated grippers or fixtures may be required for individual objects, making system configuration and product changeovers increasingly complex.
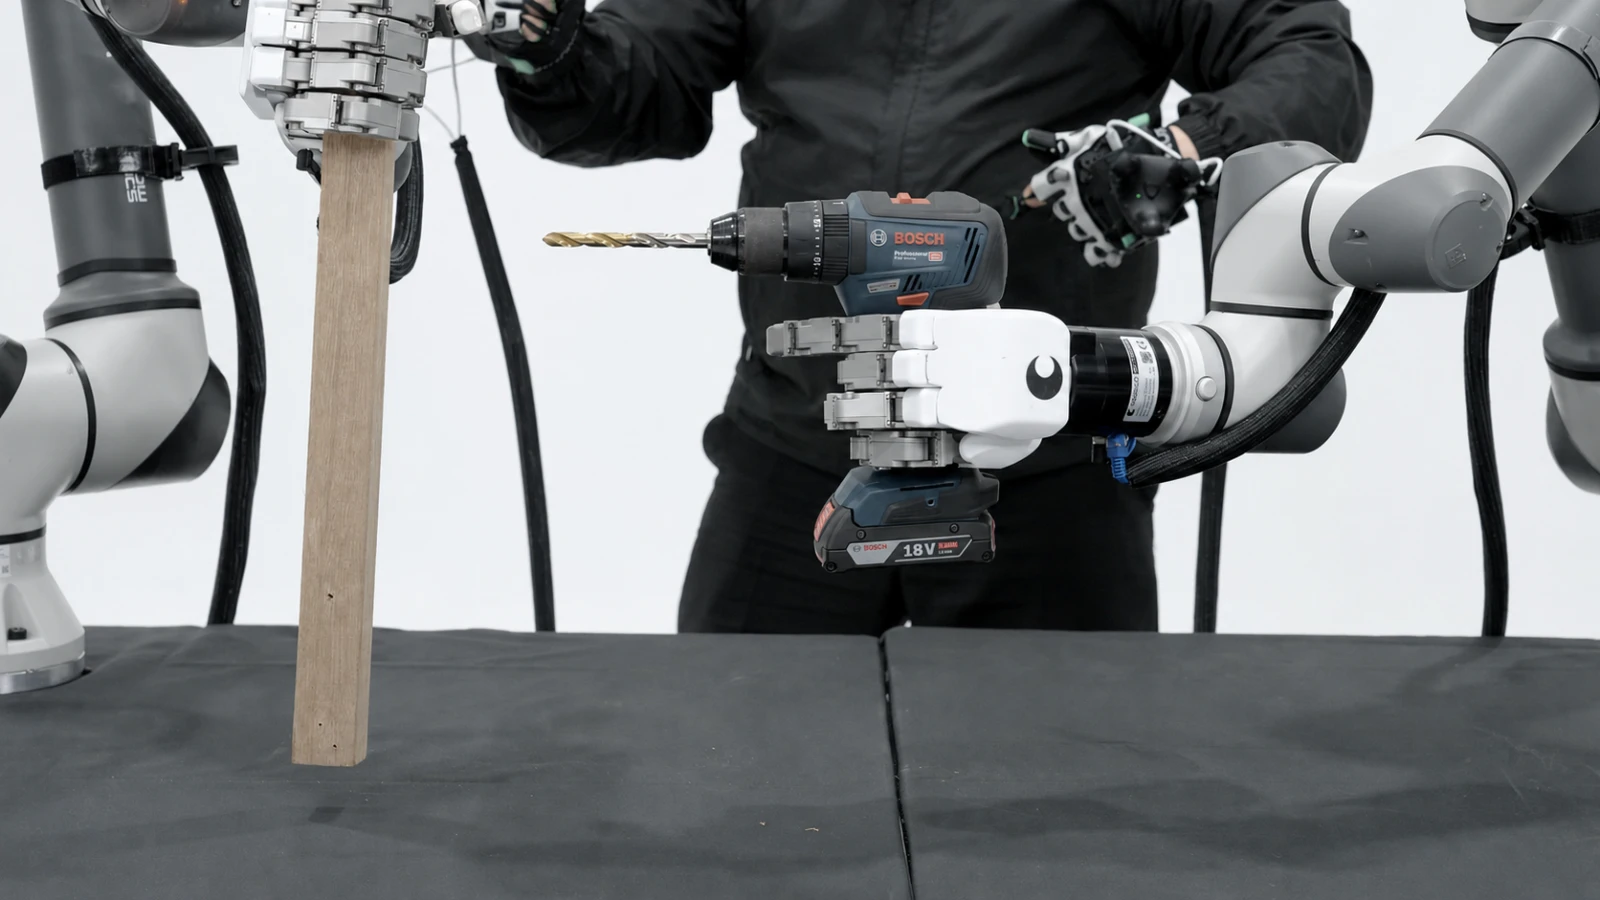
DS-PICK utilizes the various grasping configurations of the DG-3F-M, equipped with three independently driven fingers, to handle objects with different shapes and sizes.
By selecting an appropriate grasping strategy based on the object’s shape, size, and grasping position, DS-PICK reduces dependence on dedicated grippers and tool changes while expanding the range of objects that can be handled by a single automation system.
Validated with 120+ Object Types
Objects Validated
Through customer PoCs and actual picking tests, DS-PICK has validated picking feasibility for more than 120 object types with diverse shapes and sizes.
From components used in automotive, electronics, and general manufacturing to products handled in logistics and e-commerce environments, DS-PICK can apply grasping strategies suited to the characteristics of each object.

Key Applications
- Multi-part picking in automotive, electronics, and general manufacturing
- Piece Picking and Bin Picking for logistics and e-commerce
- Product sorting, alignment, and inter-process transfer
- Handling of various objects with diverse shapes
Key Performance
Objects Validated
Validated handling of more than 120 different object types through actual PoCs and picking tests
Pick Cycle Time
Within 9 seconds per object, from object recognition to grasping and transfer to the designated position
Max. Object Weight
Supports picking of objects weighing up to 7 kg
※ Cycle time and picking performance may vary depending on the object’s shape, material, size, arrangement, robot travel distance, and overall system configuration.
Scalable Multi-Object Handling from Manufacturing to Logistics
Manufacturing
Multi-Part Handling
In automotive, electronics, and general manufacturing, a wider range of production items may require dedicated grippers, fixtures, or tool changes for different components.
DS-PICK handles components of various shapes and sizes with a single articulated robotic gripper, helping to reduce gripper changes and equipment modifications associated with product changeovers while enabling flexible operation in high-mix production environments.
Application Examples
- Automotive component picking and transfer
- Electrical and electronic component handling
- Inter-process component feeding
- Component sorting and alignment
- Machine Tending
- High-mix, low-volume production
Logistics & E-commerce
Wide SKU Coverage
In logistics and e-commerce automation, the ability of a single system to handle a wide variety of products is a key factor.
By utilizing multiple grasping configurations of its articulated robotic gripper, DS-PICK can handle products with different shapes and sizes, making it suitable for Piece Picking environments that require Wide SKU Coverage.
Application Examples
- Piece Picking
- Bin Picking
- Order Picking
- Product Sorting
- Handling products across a wide range of SKUs
Versatile Object Handling
Using the DG-3F-M’s three independently driven fingers, DS-PICK configures diverse grasping poses based on each object’s shape and size.
In addition to simple parallel gripping, the finger poses can be adjusted to match the object’s geometry, expanding the range of objects that a single gripper can handle.
Object Recognition and Grasp Optimization
The 3D vision system recognizes the position and orientation of the target object inside the box and determines an appropriate grasping position and pose based on predefined information for each object.
Object shape and orientation recognition Grasping position selection for each object Grasping pose application based on object characteristics Robot approach path generation Collision and interference avoidance involving surrounding objects and the box
Failure Detection and Regrasping
In actual picking environments, overlapping objects, interference, or the grasping position may prevent an object from being picked successfully on the first attempt.
DS-PICK monitors the operation status and, if the grasp is unsuccessful, can select a new grasping position and attempt to grasp the object again.
Grasp failure detection Handling of ungraspable conditions Grasping position reselection Regrasping
High-Mix Automation
Using a dedicated End-Effector for each product or part can increase the frequency of tool changes and equipment modifications in high-mix environments.
DS-PICK is designed to handle multiple types of objects with a single articulated gripper, making it suitable for automation environments with a wide variety of products and parts.
Robot, Vision, and Gripper Integration
DS-PICK is more than a standalone gripper. It is an automation solution that integrates the robot arm, 3D vision, articulated gripper, and picking software required for real-world picking automation.
3D Vision → Object Recognition → Grasp Planning → Robot Motion → Gripping → Pick & Place
The entire picking process—from object recognition and grasping position selection to robot motion, grasping, and transfer—is integrated into a single system.