DELTO SOLUTION

Delto Solution

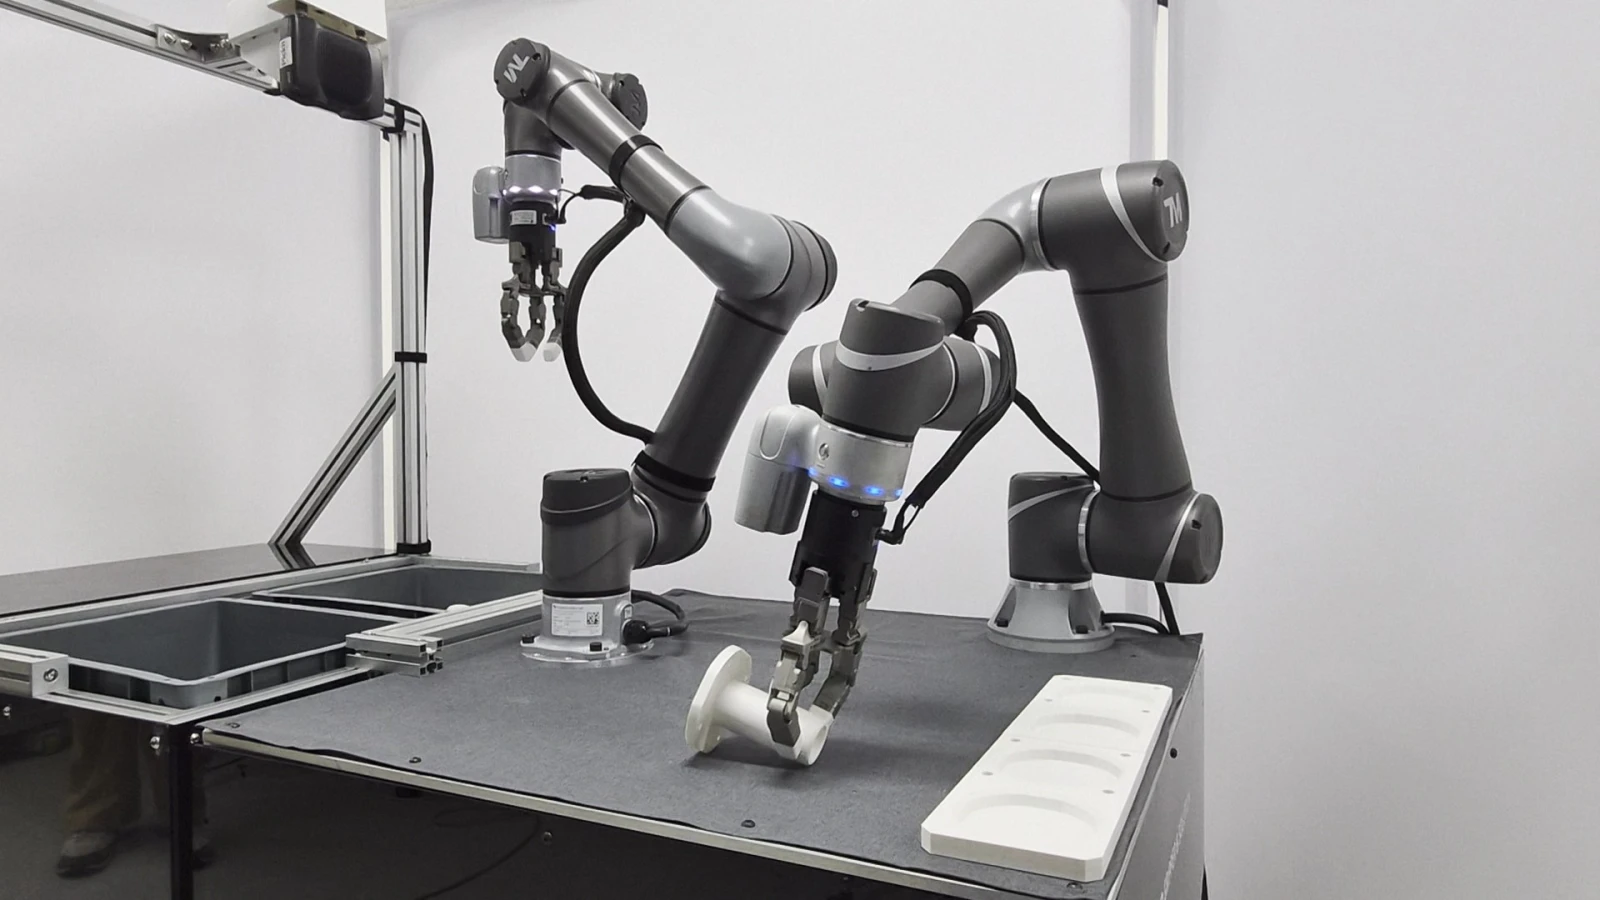
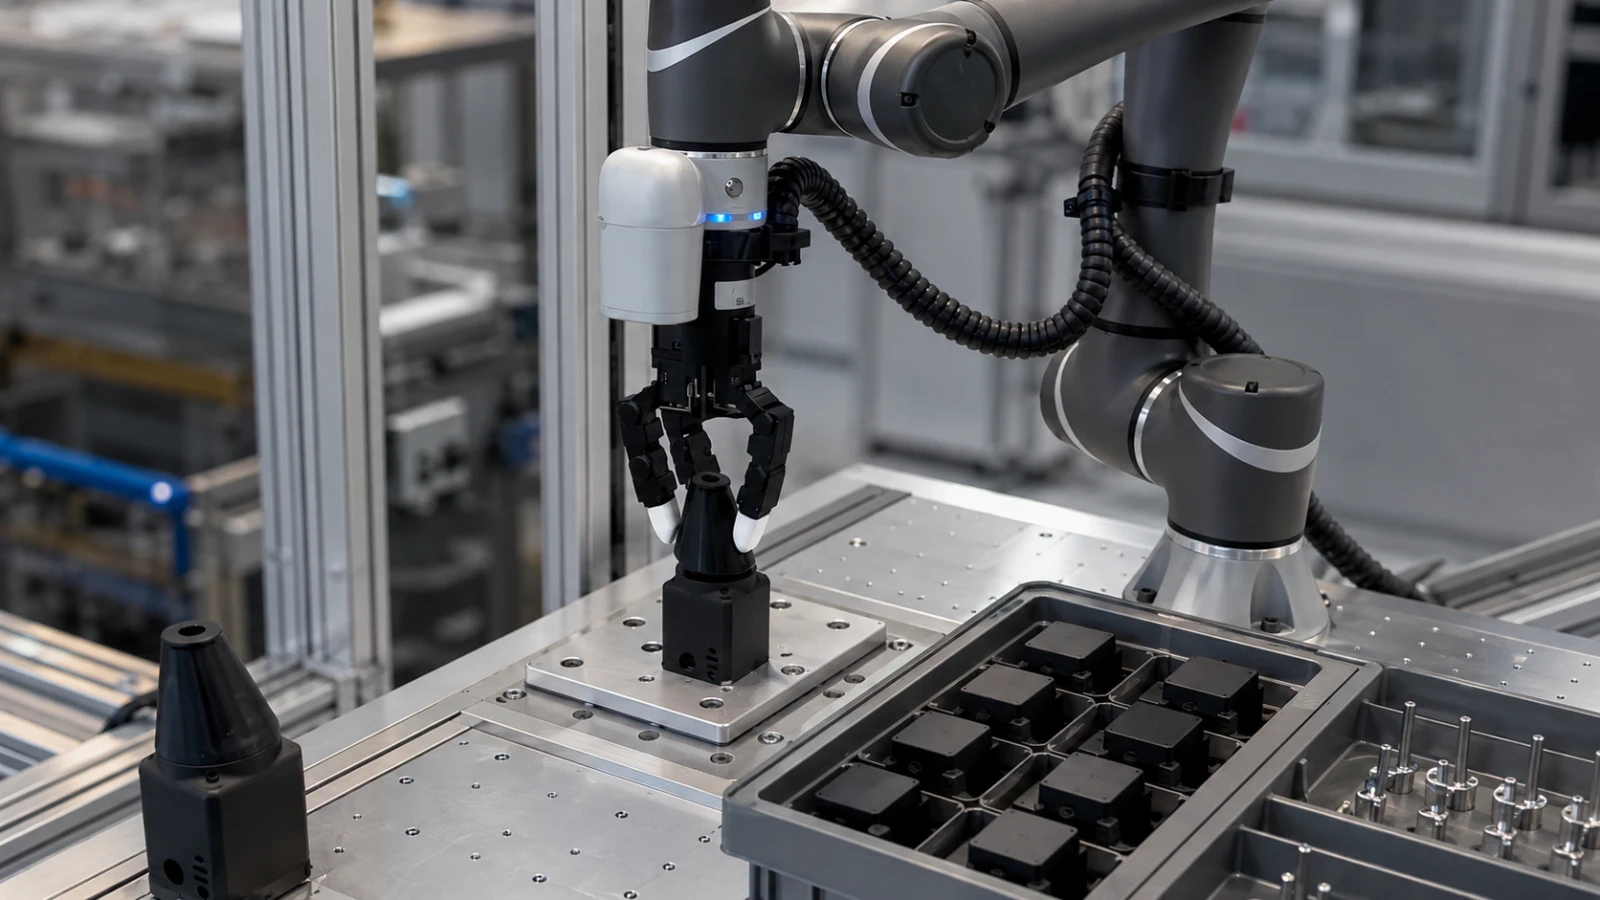
Delto Solution (DS) is a robotic automation solution that leverages TESOLLO’s articulated robotic grippers, robotic hands, and control technologies to assess and validate automation feasibility for real-world processes.

Process Automation Solutions Powered by Articulated Robotic Hands and Grippers

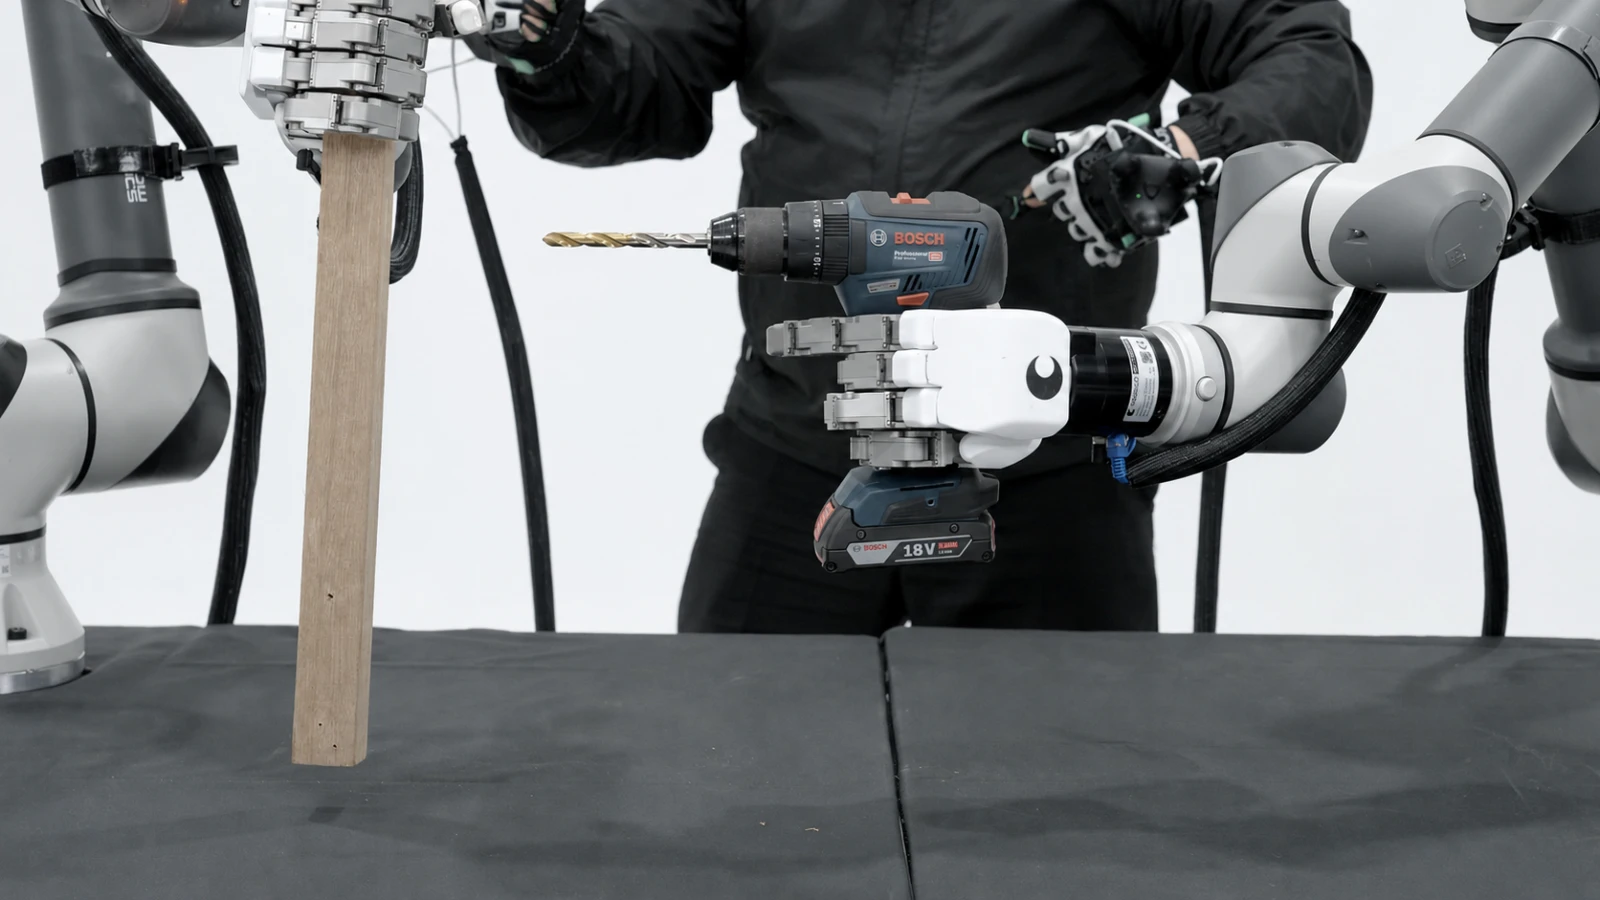
We analyze the objects to be grasped or manipulated and the operating conditions, then validate technical feasibility through testing with actual samples and proof-of-concept (PoC) projects. Validated solutions can be scaled for deployment on production lines in collaboration with TESOLLO’s SI partners or the customer’s designated SI partner. Depending on the target application, Delto Solution comprises DS-PICK for automated picking, DS-ASS for automated assembly, and DS-Dual Arm for dual-arm robot teleoperation and manipulation data collection. Before implementing a full-scale automation system, TESOLLO first evaluates technical feasibility using the actual process and target objects. After analyzing the customer’s process information, we promptly conduct preliminary tests using actual samples and provide a report summarizing the validation results and recommended implementation approach. If necessary, additional performance validation can then be conducted through a PoC in an environment that closely replicates the actual process. Once validation is complete, the solution can be deployed on a production line in collaboration with an SI partner.

IMPLEMENTATION PROCESS
STEP 1
Process Analysis
We analyze the process targeted for automation and its requirements. Key conditions—including the target objects’ shape, size, and weight, the operating method, and the required cycle time—are reviewed to assess the solution’s feasibility.
STEP 2
Preliminary Sample-Based Validation
We quickly assess feasibility using actual target samples. Samples provided by the customer are tested directly with TESOLLO’s robotic grippers and solutions to verify whether they can be grasped and whether the required tasks can be performed. This allows technical feasibility and key considerations to be identified before a full-scale project begins.
STEP 3
Validation Report
We provide a validation report summarizing the test results and recommended implementation approach. The report presents key test results—including the grasping method, task performance, and cycle time—as well as the recommended system configuration and any areas requiring further validation. Based on the validation results, customers can determine whether to proceed with a PoC and define the direction of the project.
STEP 4
PoC
If necessary, we conduct a PoC based on the actual process. We configure the required systems—including robots, grippers, and vision systems—and perform repeated tests in an actual or comparable operating environment to validate the solution’s performance and reliability. The PoC confirms the solution’s technical viability for deployment on a production line.
STEP 5
Production Line Deployment
We work with SI partners to scale validated solutions for deployment on production lines. Once validation and the PoC are complete, deployment at actual production and logistics sites can proceed in collaboration with TESOLLO’s SI partners or an SI partner designated by the customer. TESOLLO provides validated robotic grippers and solution technologies, along with the technical support required during system implementation by the SI partner.

Ready to integrate a dexterous hand into your platform?

Talk to our engineering team about gripper selection, integration, and lead times.