DG-5F-M
A 20-DoF, 5-finger anthropomorphic robotic hand with high-torque actuation for dexterous manipulation and precise object handling.

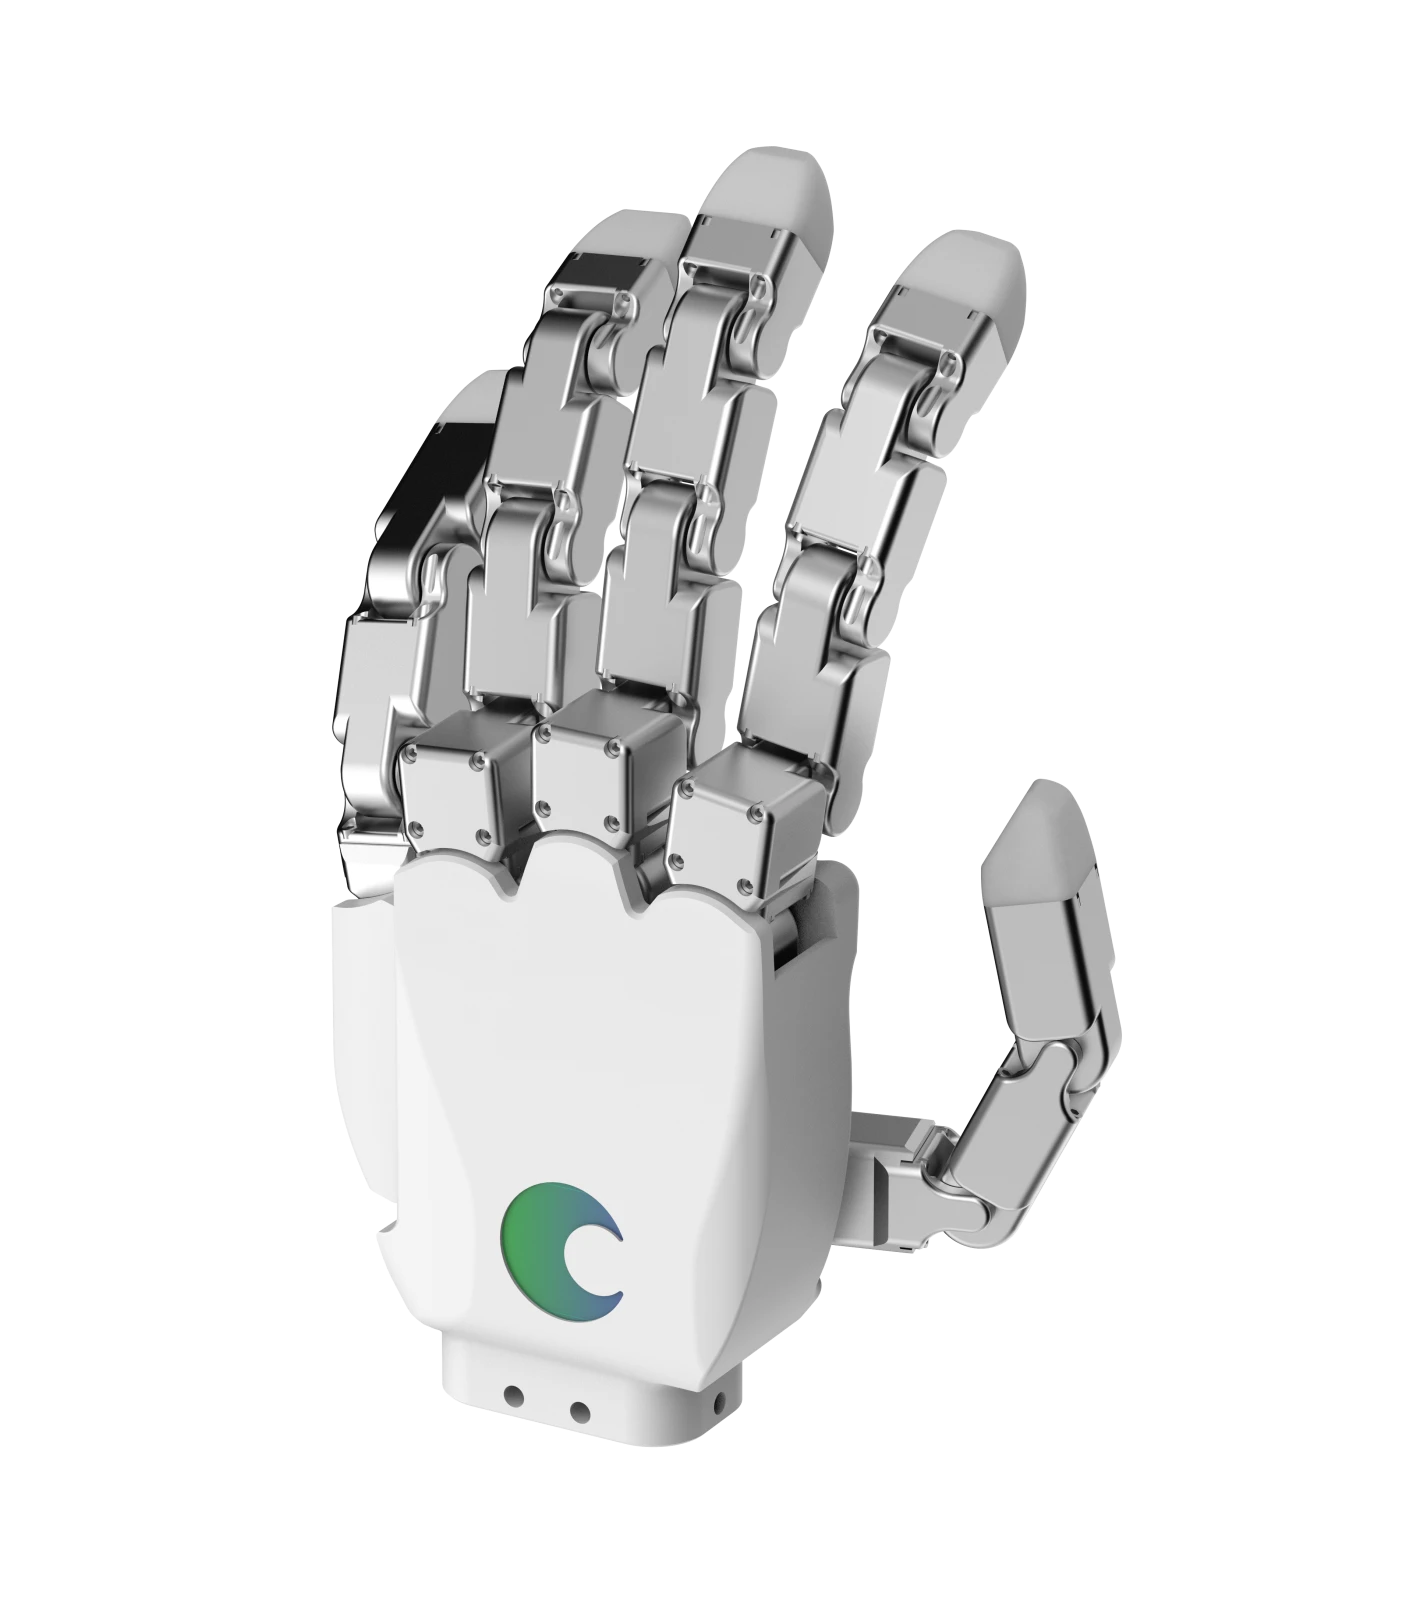
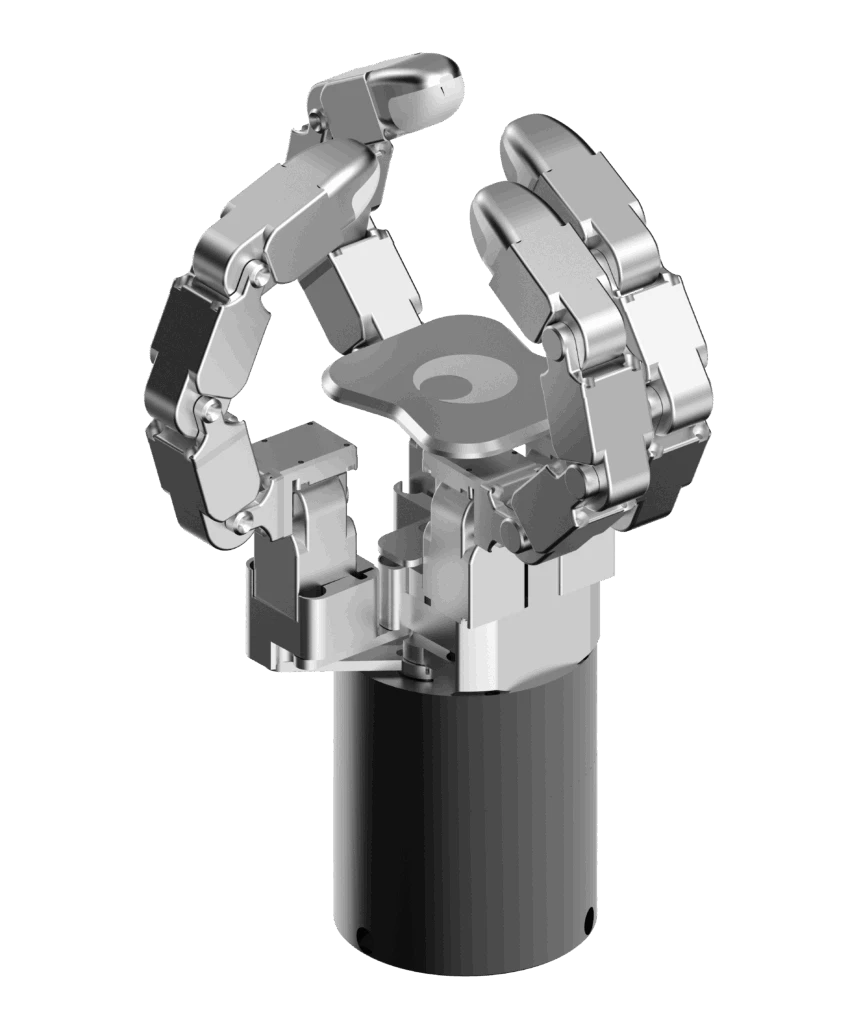
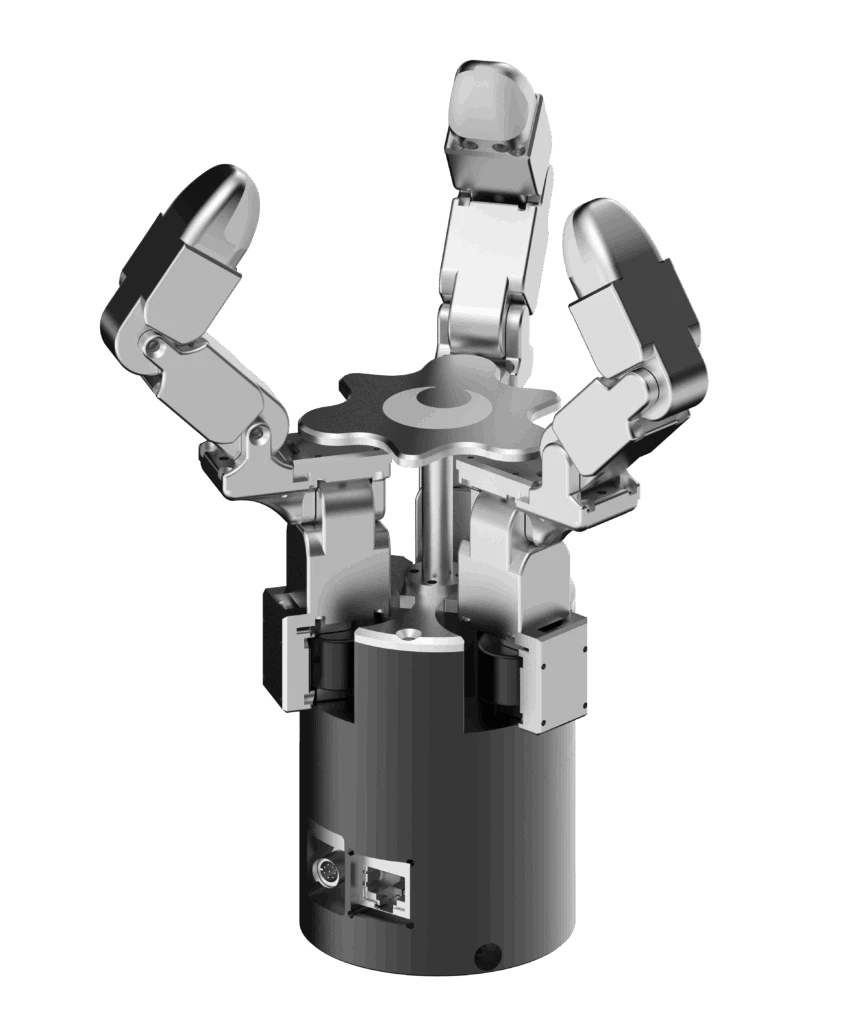
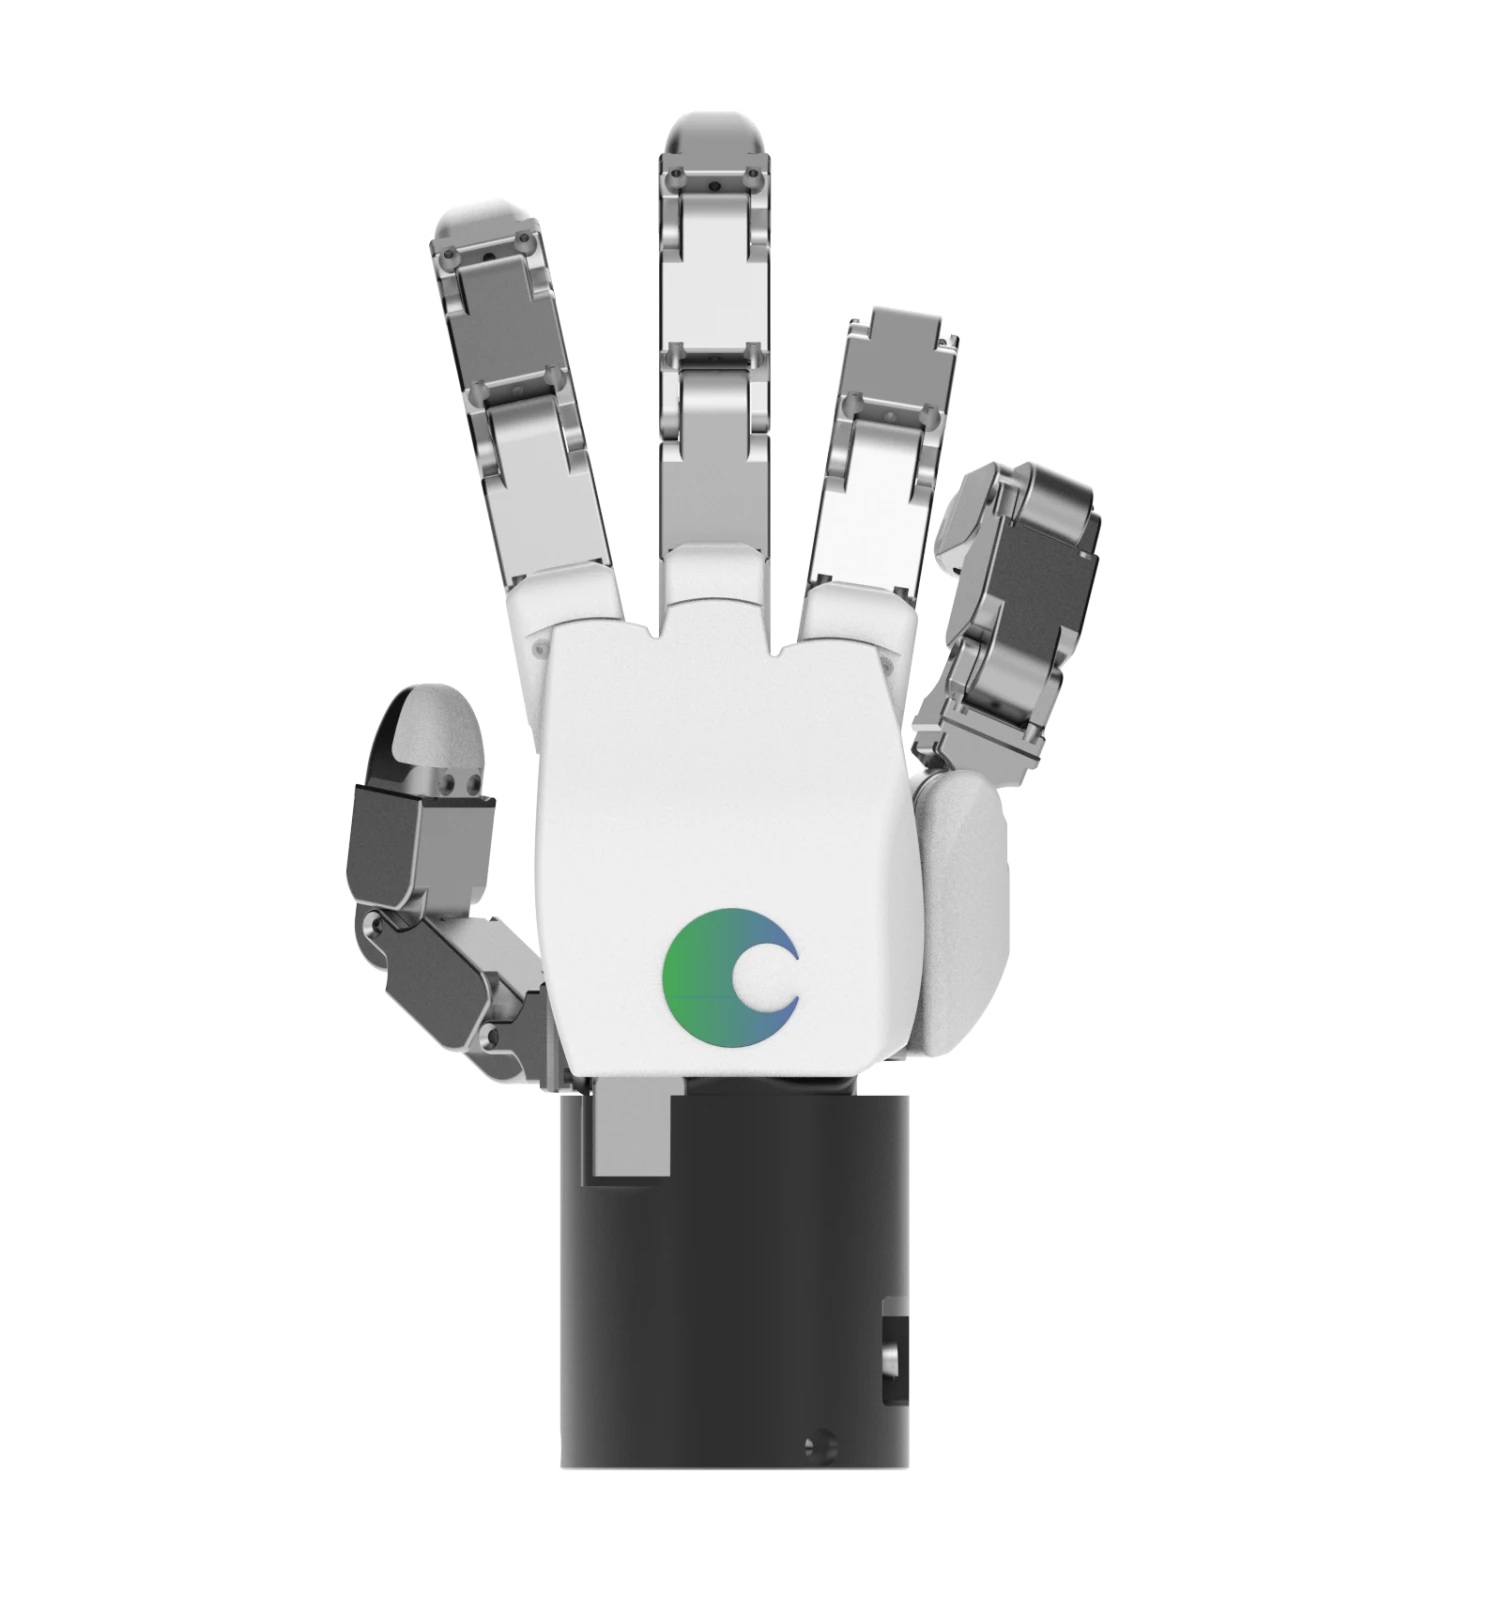
The DG-5F-M is a fully actuated, 5-finger anthropomorphic robotic hand with 20 degrees of freedom (DoF), designed for high-dexterity, human-like manipulation. Its independently controlled joints and high-torque actuation provide both the flexibility and force required for complex grasping, precise object handling, and demanding manipulation tasks.
With coordinated multi-finger control, the DG-5F-M supports intuitive tool use and powerful manipulation of objects with different shapes and sizes. It is well suited for advanced robotics research, industrial automation, and service robotics applications where precise control, powerful manipulation, and flexible task execution are required.
Independent Joint Control
Each of the 20 joints is driven by its own integrated actuator, enabling fully independent joint control without inter-joint mechanical coupling. This architecture enables precise finger-by-finger motion, coordinated multi-finger manipulation, and complex grasping behaviors.
Human-Like Design
Modeled after the size and proportions of an adult male hand, the DG-5F-M is designed for operation in human-oriented environments. Its anthropomorphic form enables natural interaction with tools, devices, and workspaces designed for human use.
Multiple Grip Modes
Supports a wide range of grip patterns, including:
Pinch Grip: Fingertip grasping for small objects Power Grip: Firm, full-hand grasping for stable object handling Precision Grip: Precise manipulation of small objects using coordinated fingertip control
Different grip configurations can be selected according to object size, shape, and task requirements.
Configurable Sensor Options
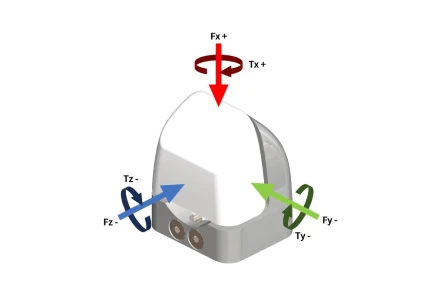
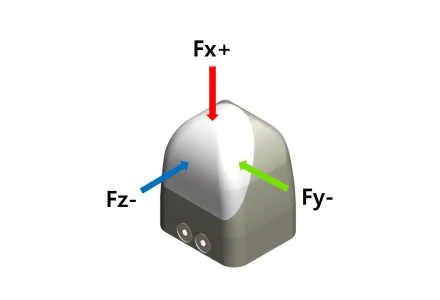
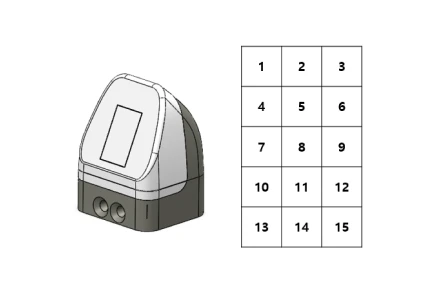
Optional 6-axis F/T, 3-axis force, and tactile sensors can be integrated at the fingertips according to application requirements. These sensor options provide real-time force and tactile data that users can utilize to develop force-based control, slip detection, tactile sensing, and interaction algorithms for their applications.
Control and System Integration
Provides a user-friendly control interface and ROS 2 integration support, enabling straightforward integration with existing robotic platforms, simulators, and control systems.
Robust Materials and Durability
Built from high-strength, lightweight materials for reliable performance during repeated and dynamic operation. The DG-5F-M is suitable for both industrial and research applications.