CUSTOM DEVELOPMENT
DG-C is designed for production-line deployment and large-scale projects. Custom development is available for projects with defined production or deployment plans; one-off gripper development is not offered.
OVERVIEW
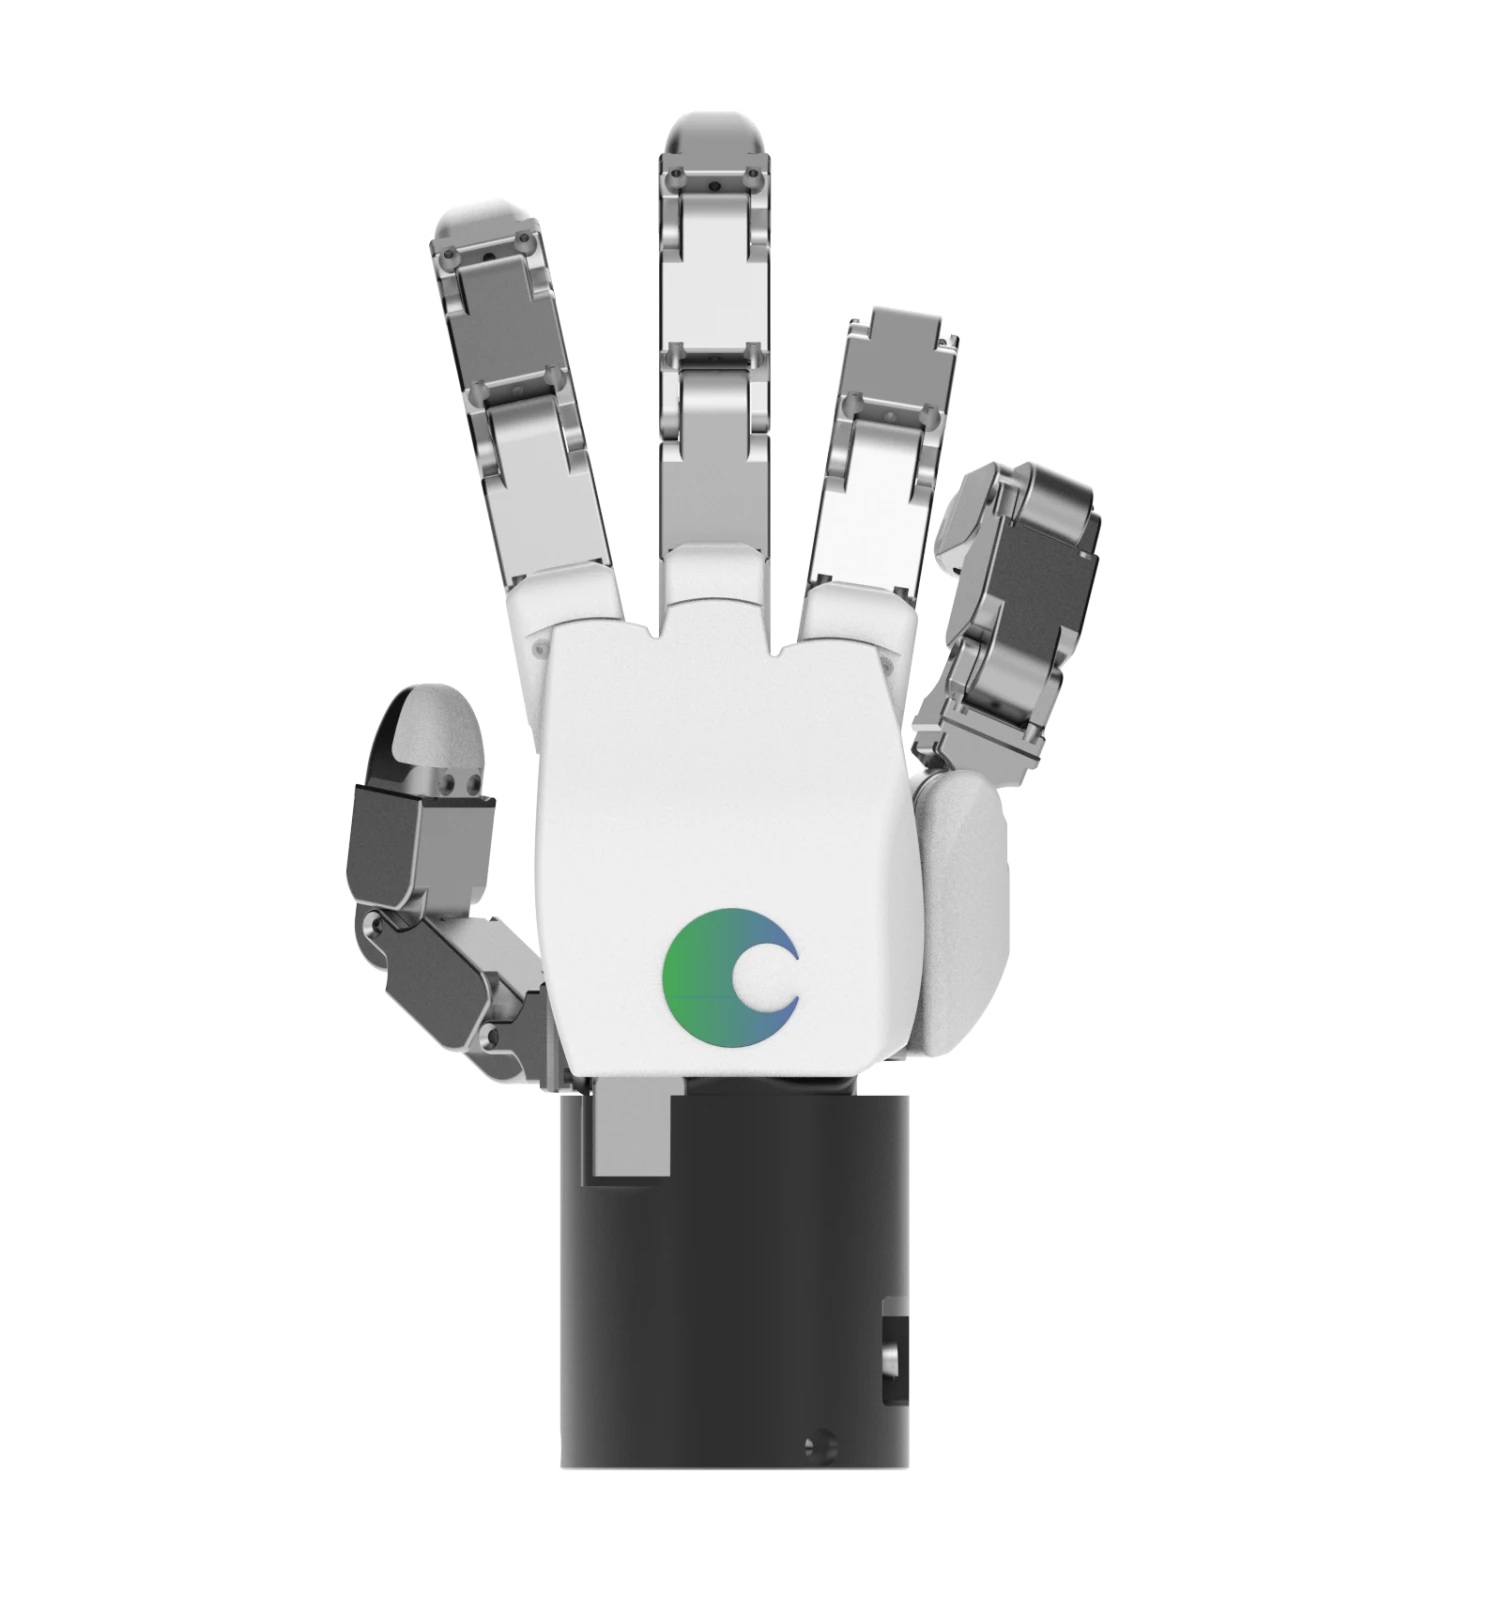
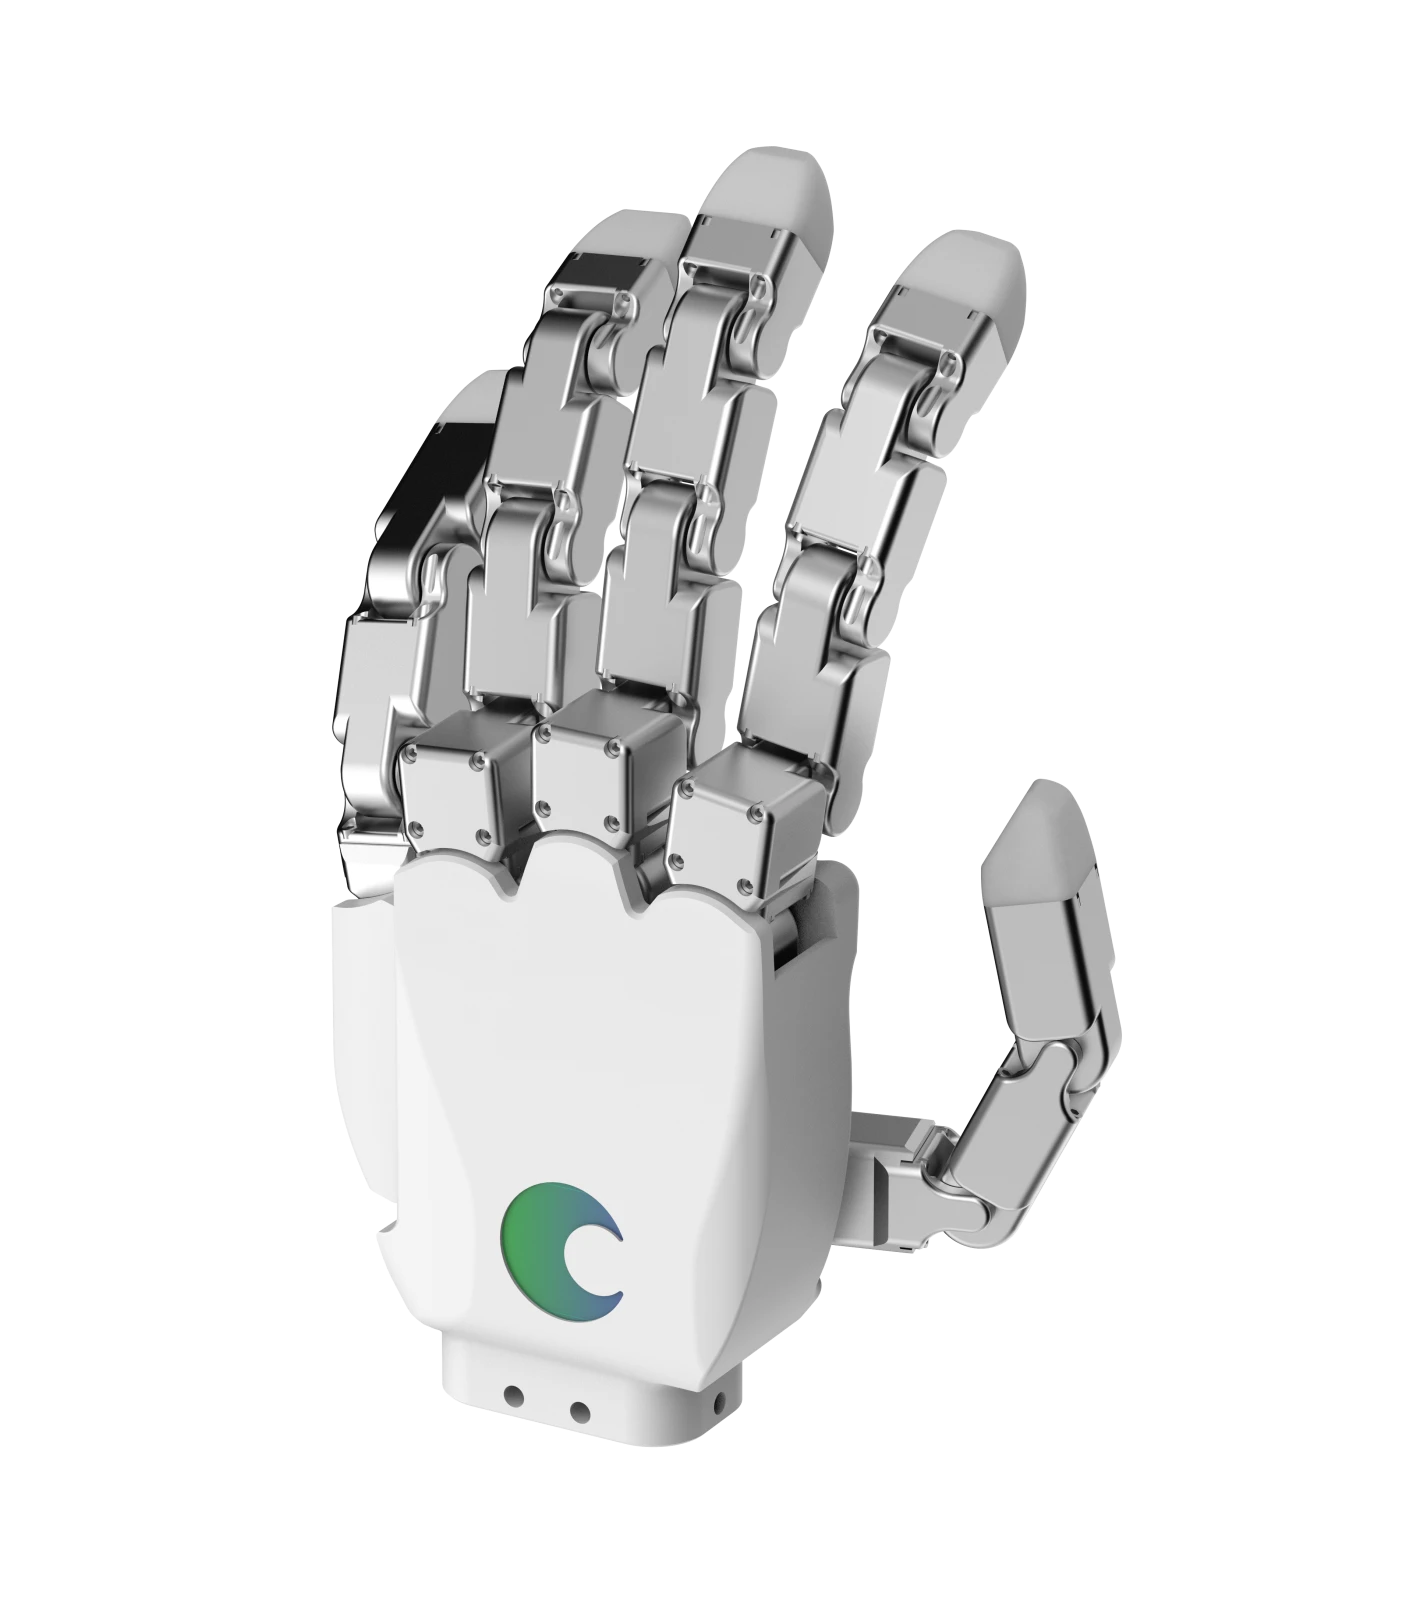
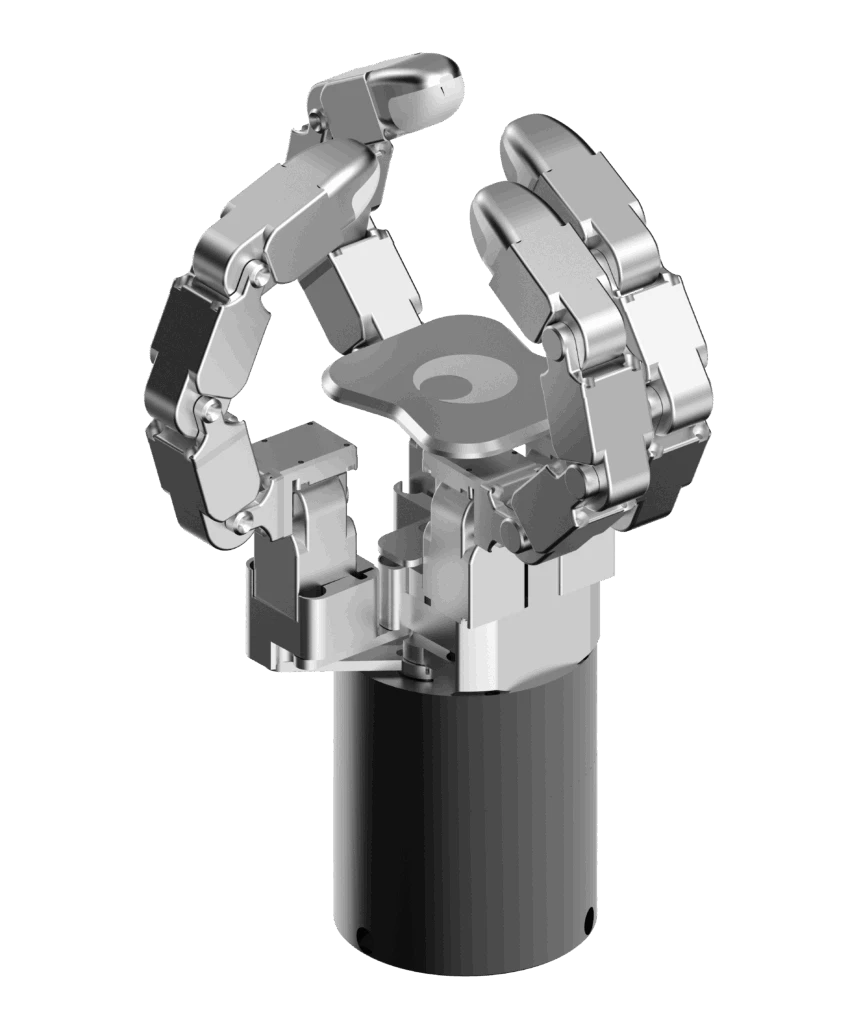
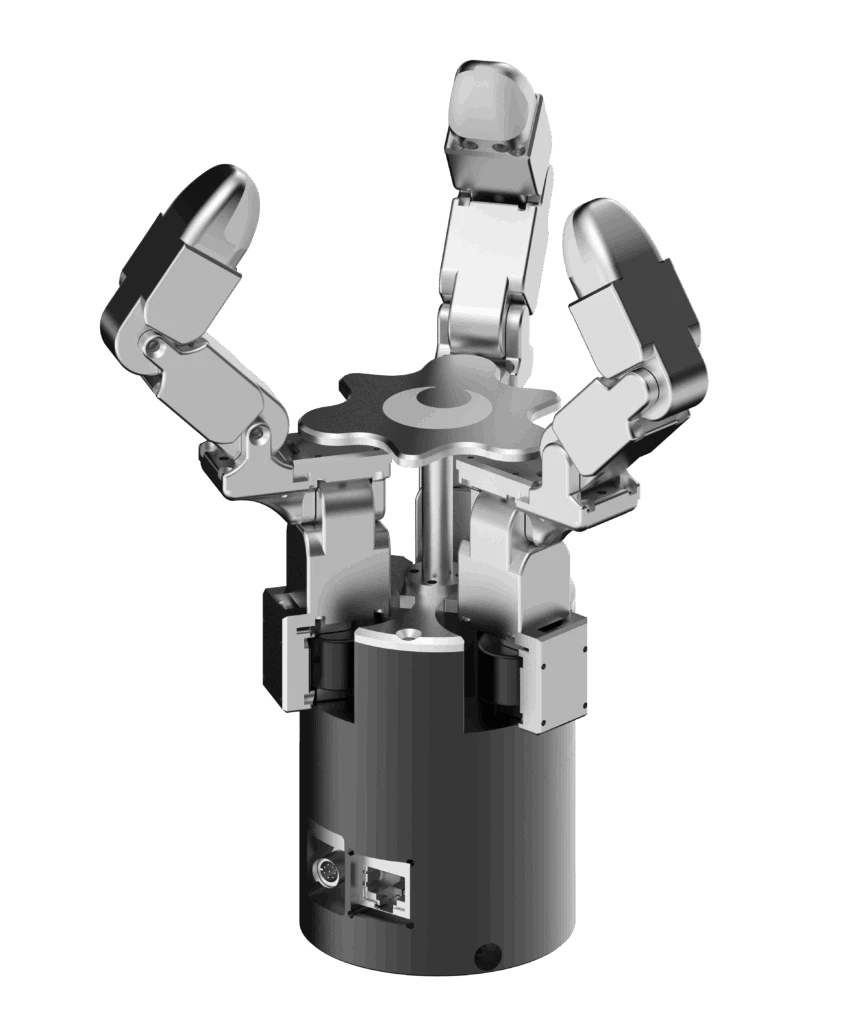
DG-C is a custom end-effector platform built on TESOLLO’s proprietary high-torque-density actuators and drive technology. Unlike the standard DG Series, DG-C is developed around the requirements of each application, enabling custom multi-joint grippers and robotic hands with application-specific structures, configurations, and form factors.
01 — ACTUATION
TESOLLO High-Torque-Density Actuators
Proprietary actuation platform
02 — ARCHITECTURE
2F · 3F · 4F · 5F · Custom
Finger count, joint configuration, and form factor
03 — SENSING & TOOLING
Tactile Sensor · Fingertip · Suction · Fingertip Changer
Application-specific sensing and end tooling
Custom-Built Architecture
Finger count, joint configuration, form factor, and mechanical structure can be tailored to the requirements of each application.
High-Torque-Density Actuation
Built on TESOLLO’s proprietary actuator technology to enable compact, high-DoF designs with powerful and precise joint motion.
Application-Specific Design
Developed around the customer’s target task, robot platform, workspace, and handling requirements rather than a fixed gripper architecture.
Sensor & Fingertip Integration
Sensors, fingertips, fingertip changers, and other end-tooling components can be configured or customized to match the application and integrate with the DG platform.