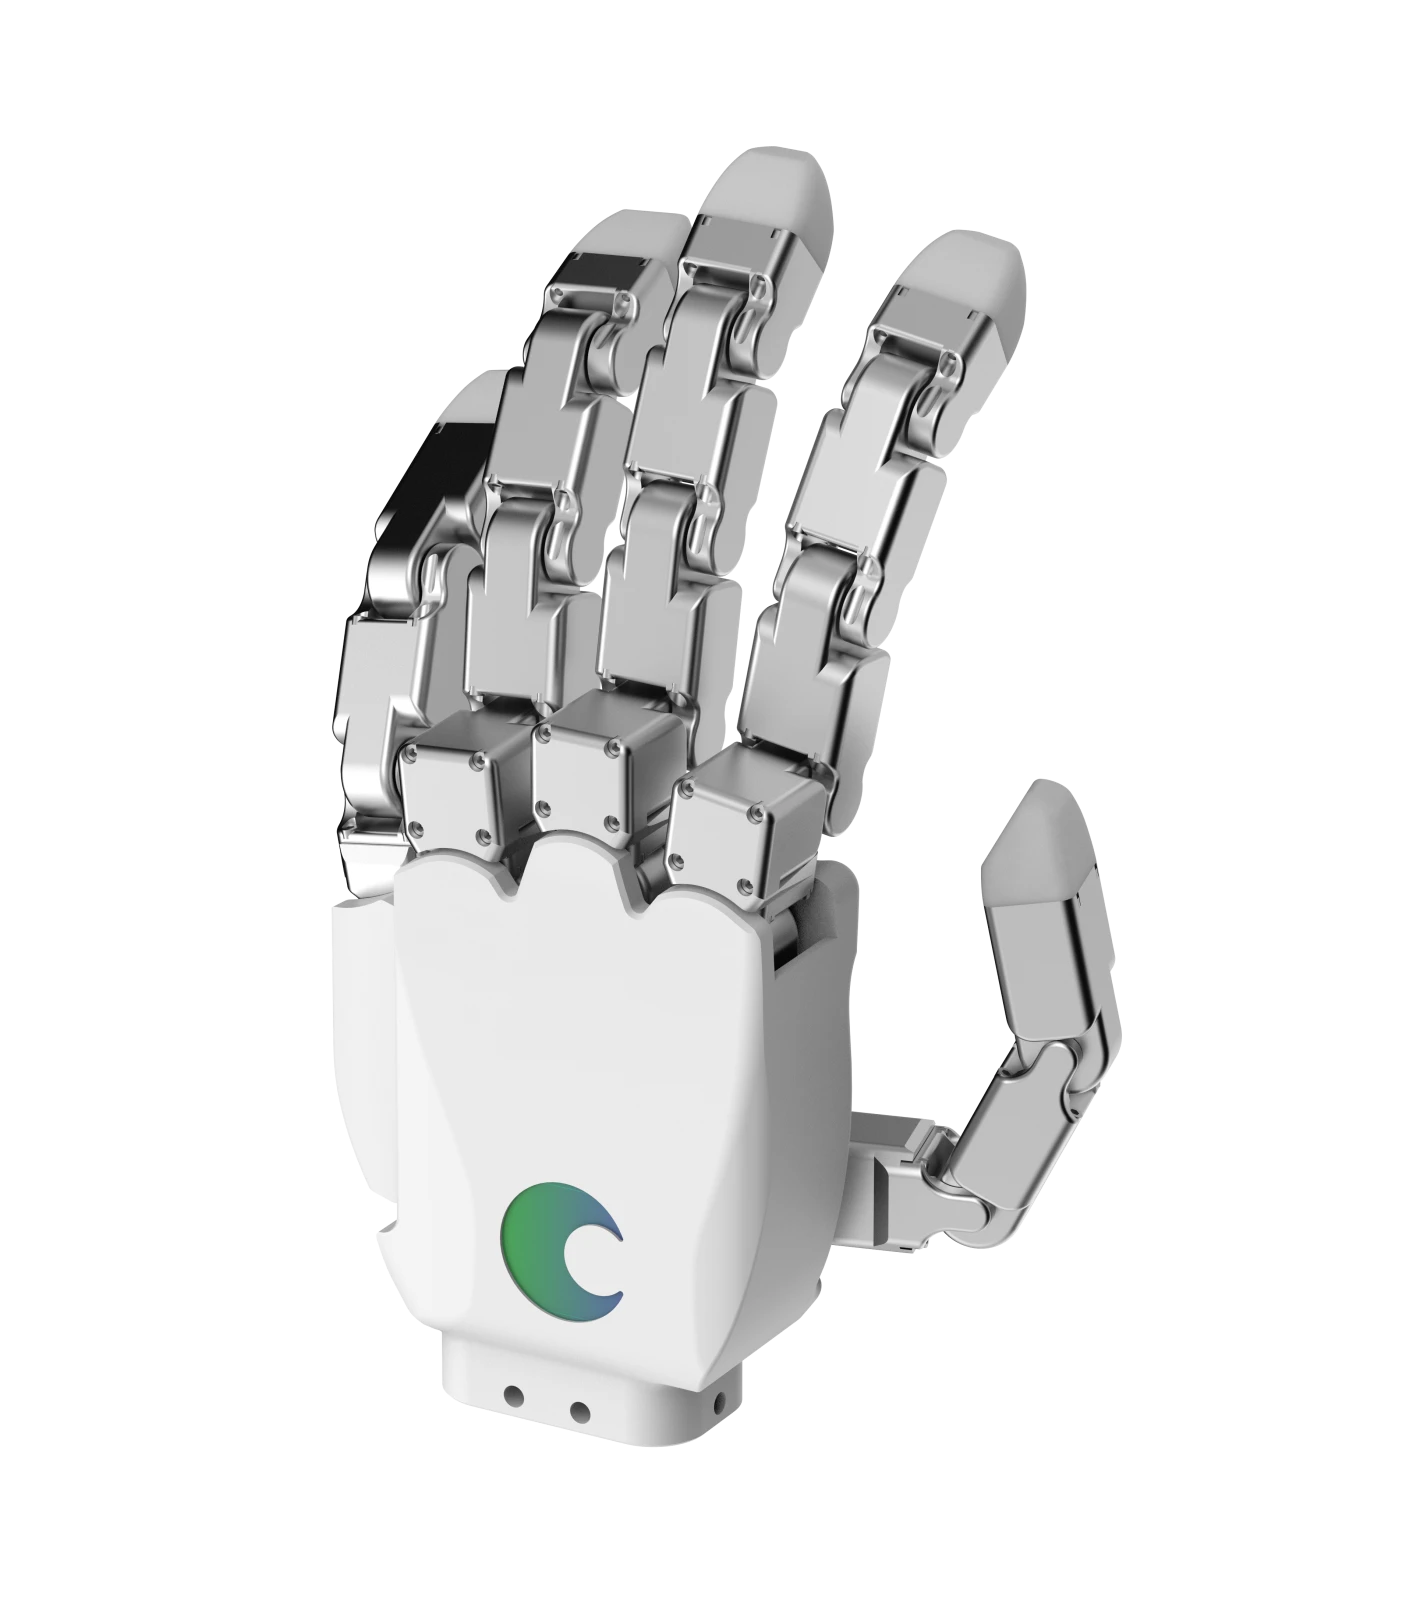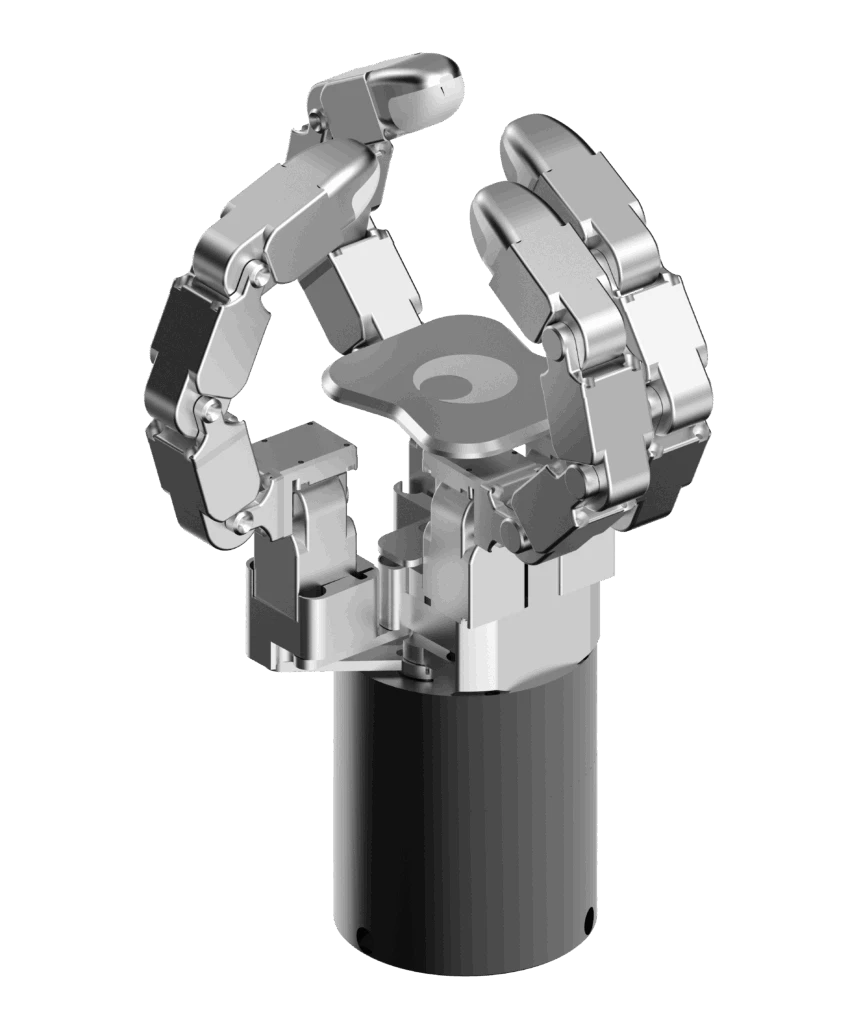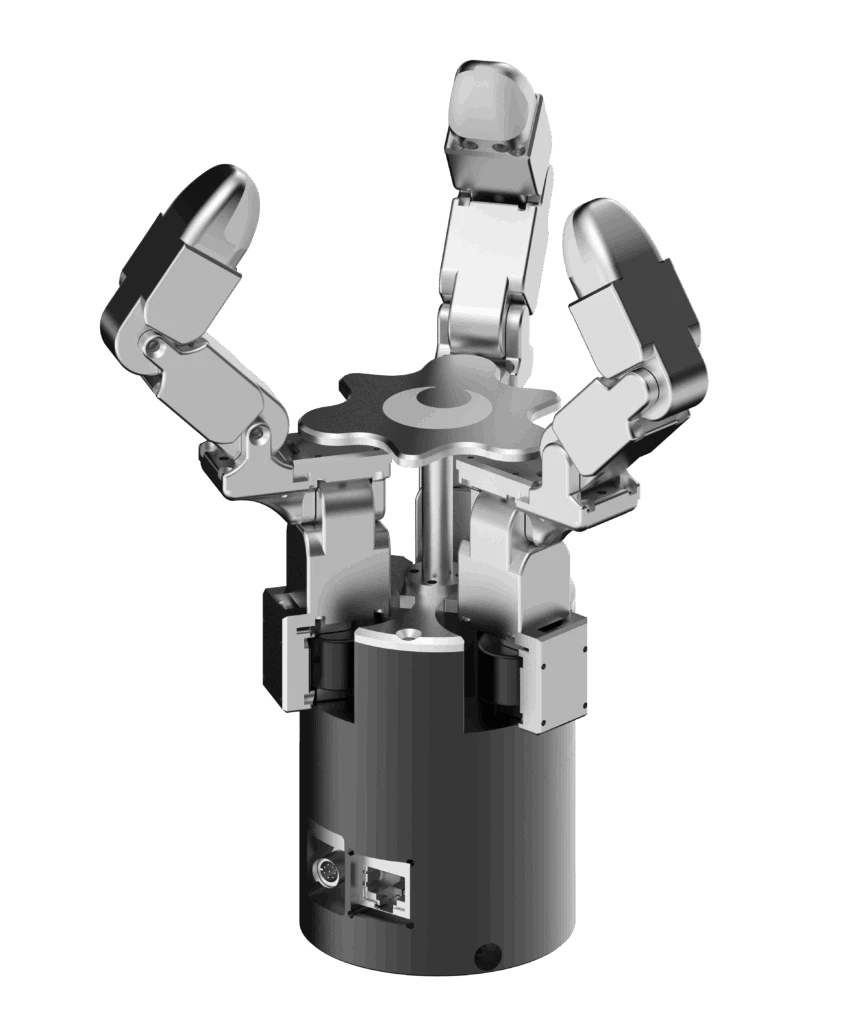
DG-3F-M
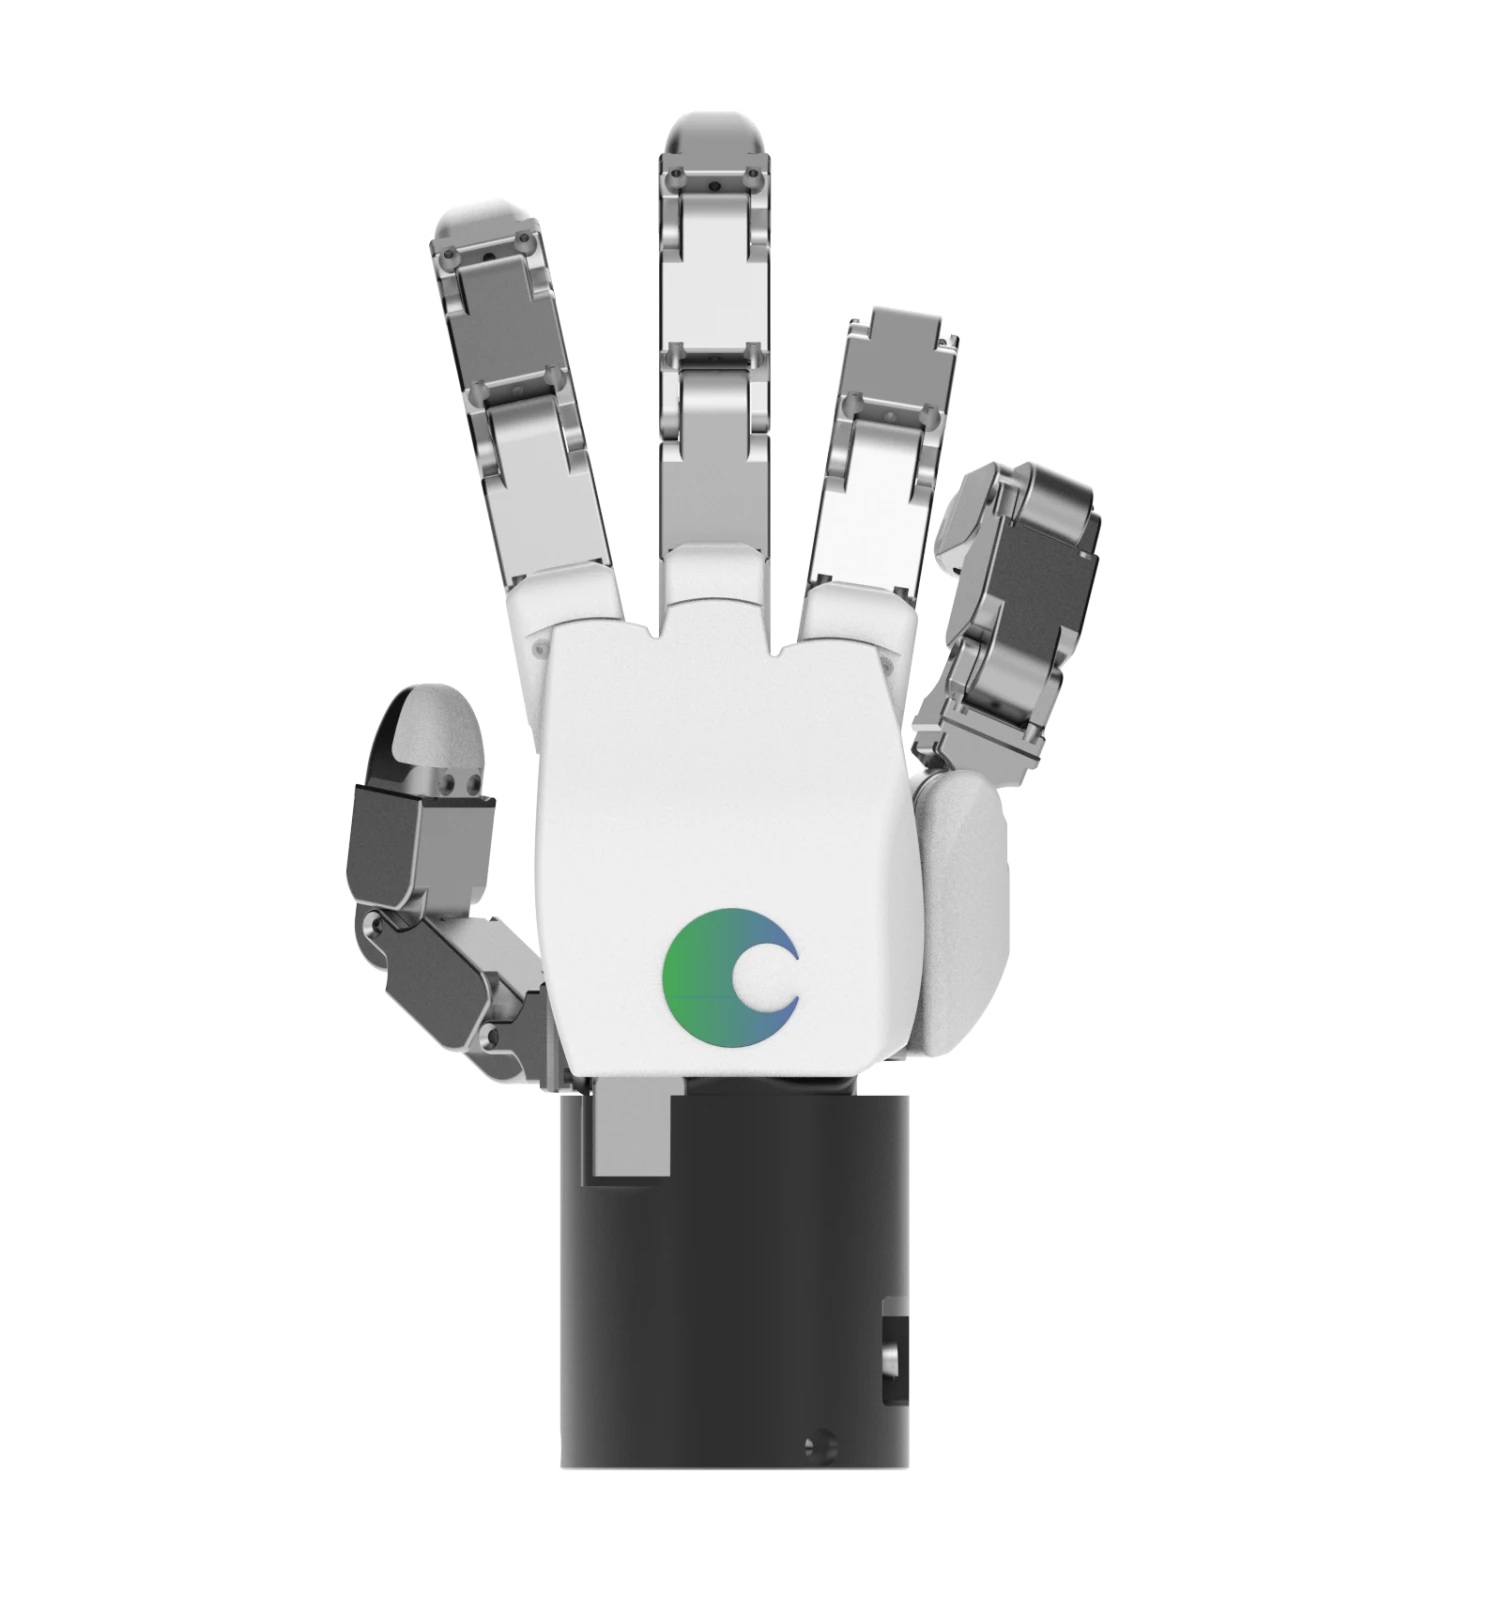
A 12-DoF, 3-finger robotic gripper engineered for industrial automation, combining powerful gripping, high durability, and precise multi-joint control.
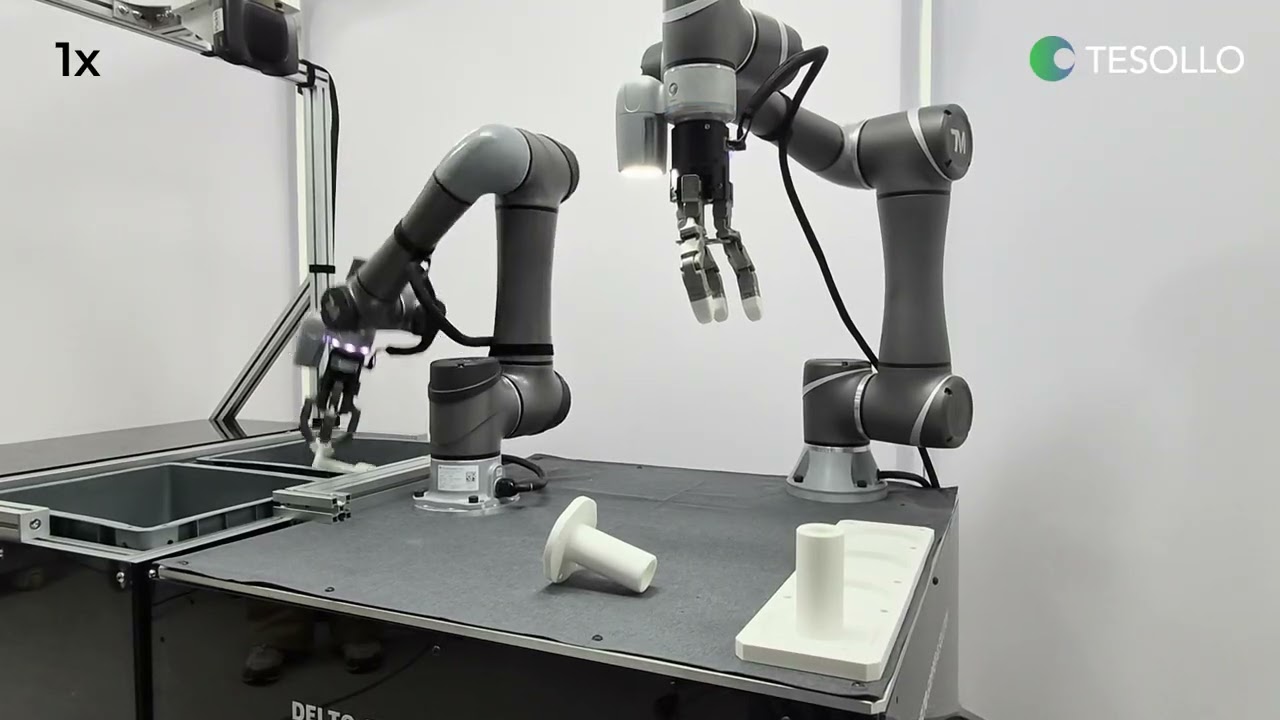
The DG-3F-M is an industrial-grade 3-finger robotic gripper with 12 degrees of freedom (DoF), engineered for reliable and powerful manipulation in demanding automation environments. Its independently controlled multi-joint fingers enable precise gripping while adapting to objects with different shapes, sizes, and orientations.
Built for durability and continuous industrial use, the DG-3F-M combines high-torque actuation with a modular structure that simplifies maintenance and supports stable performance over extended operation. Its versatile grasping capability makes it well suited for picking, handling, assembly, machine tending, and other industrial automation tasks where both gripping force and flexibility are required.
High-Performance Actuation
High-efficiency BLDC motors and reinforced high-strength gears provide precise control and robust actuation for demanding industrial tasks. Each finger delivers up to 2 Nm of torque, while the drivetrain is designed to withstand more than 3 million operating cycles under industrial-use conditions.
Fully Modular Design
Each finger and actuator module is designed for easy assembly and disassembly using standard fasteners. Individual modules can be maintained or replaced without dismantling the entire gripper, helping reduce repair time, system downtime, and maintenance effort.
Versatile Gripping and Manipulation
Supports multiple gripping modes for a wide range of object-handling tasks. Parallel Mode provides conventional industrial gripping, while Smooth Mode enables more controlled handling of delicate or fragile objects. Continuous motion and post-grip adjustment allow objects to be repositioned precisely after grasping.
Position and Status Feedback
Provides joint and position status information for accurate target-position monitoring and reliable motion execution. Target-arrival detection enables the system to verify commanded motions, while configuration and operational data can be retained for efficient system recovery.
Control and System Integration
Provides a C/C++ SDK for integration with a wide range of robotic platforms and automation systems. An intuitive user interface simplifies configuration, operation, and system setup for both development and deployment.