DG-5F-S
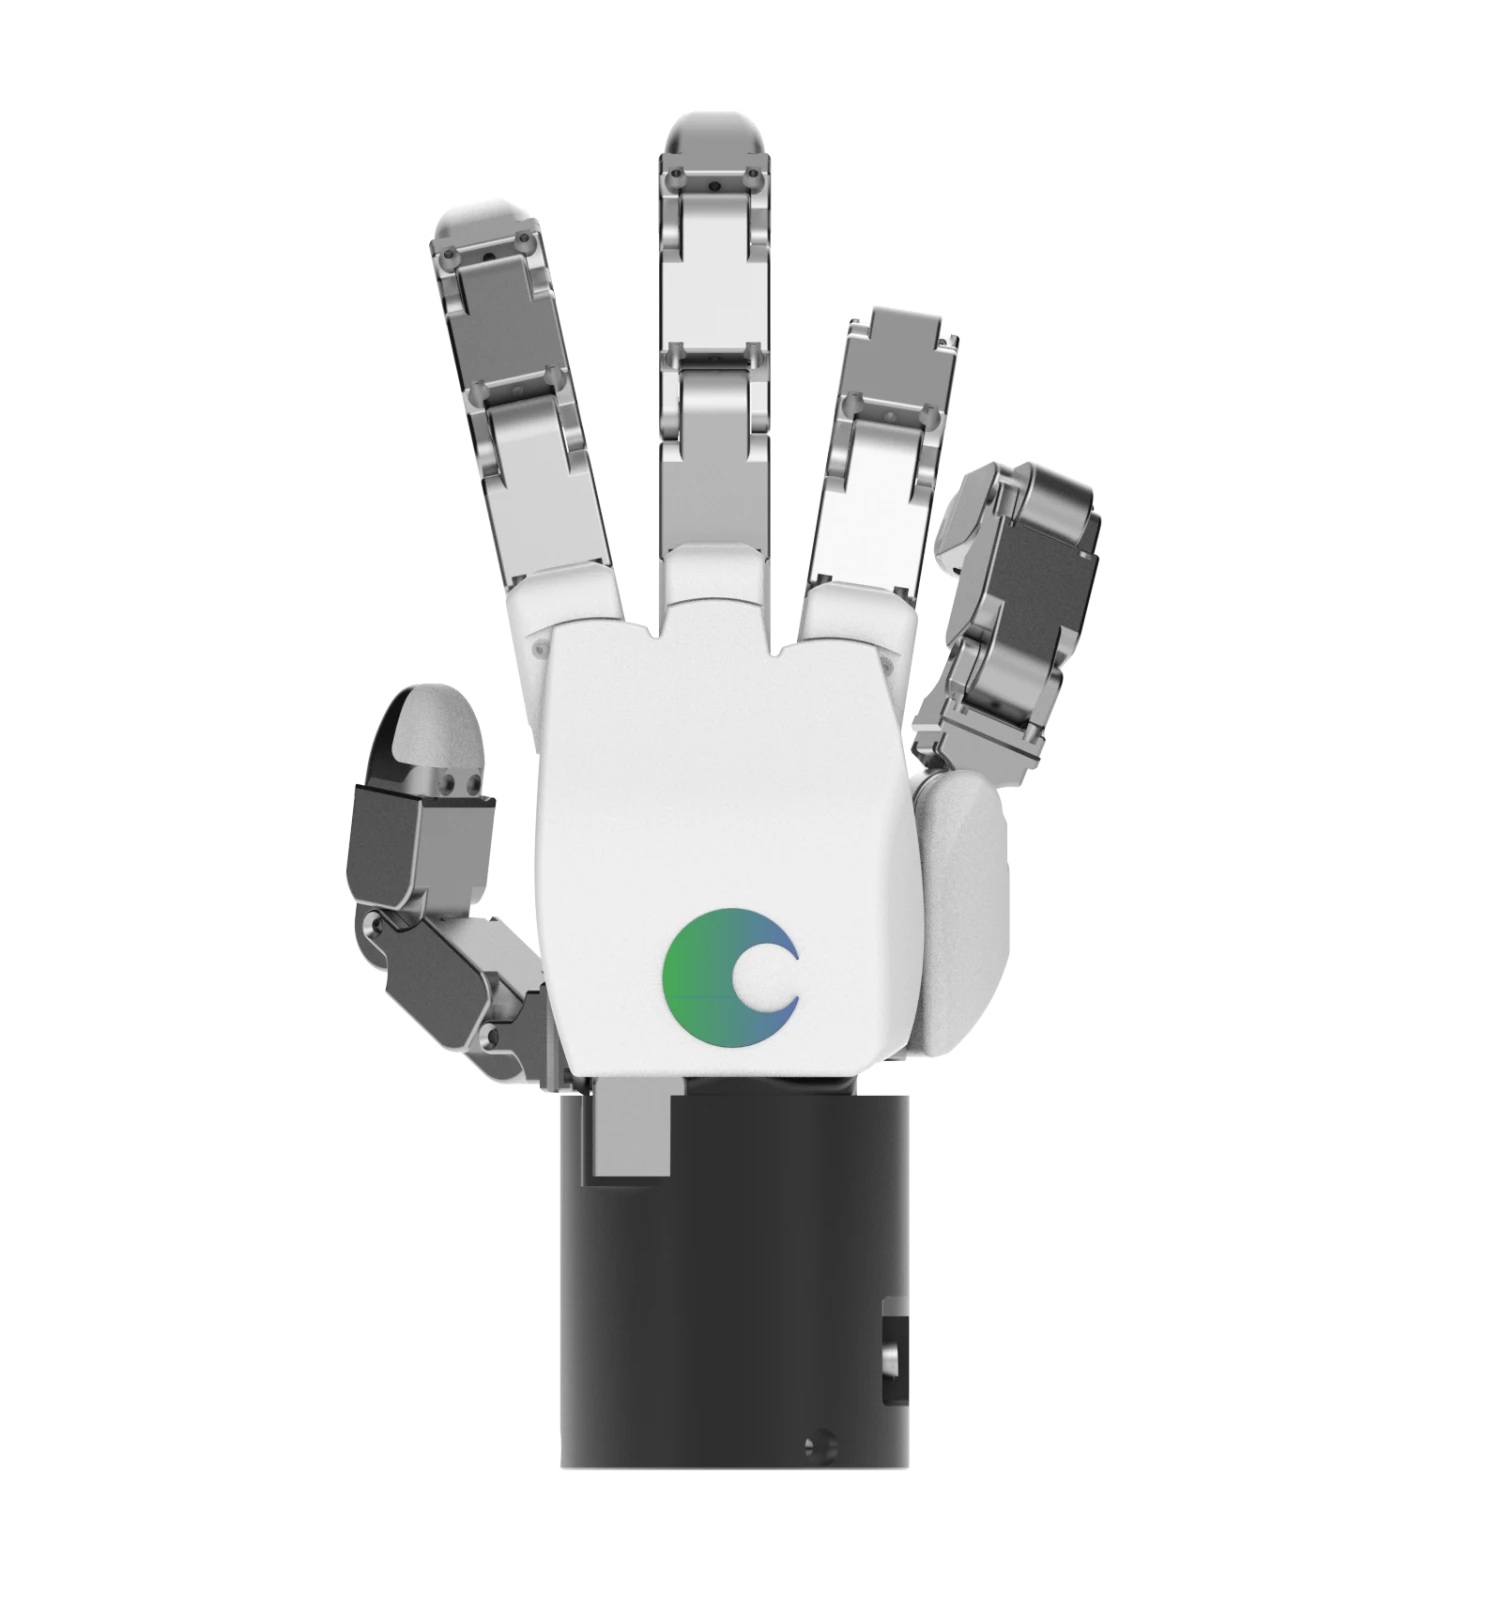
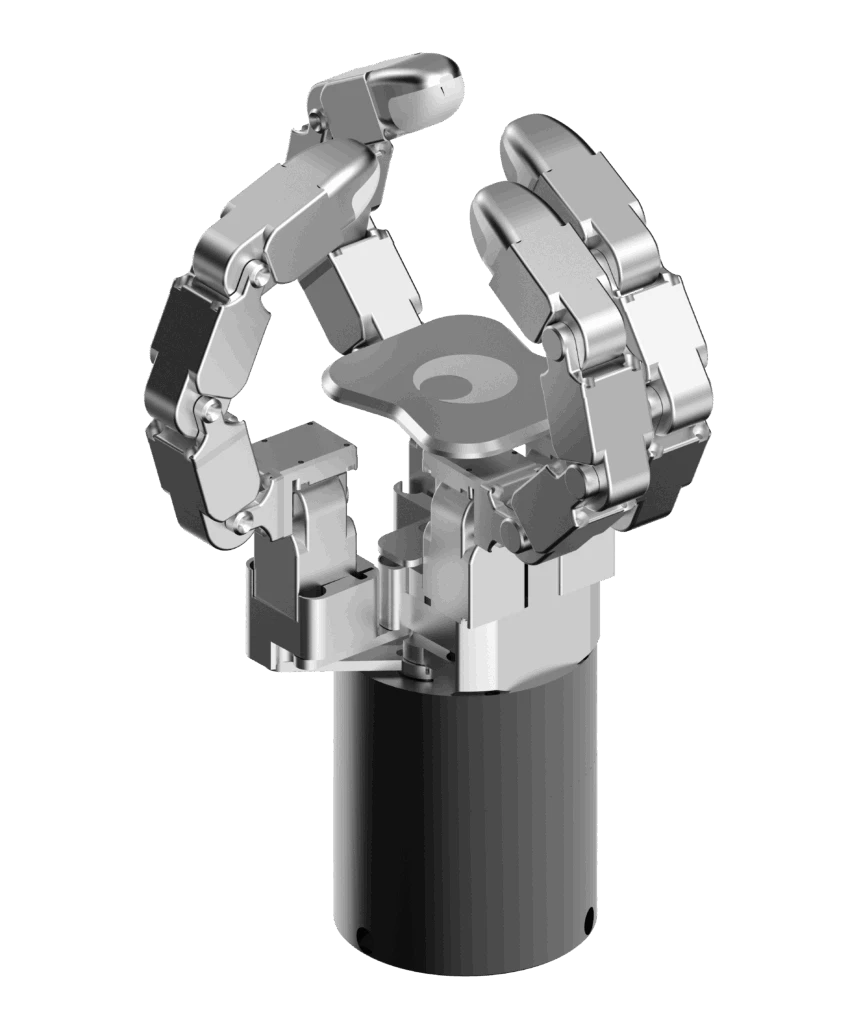
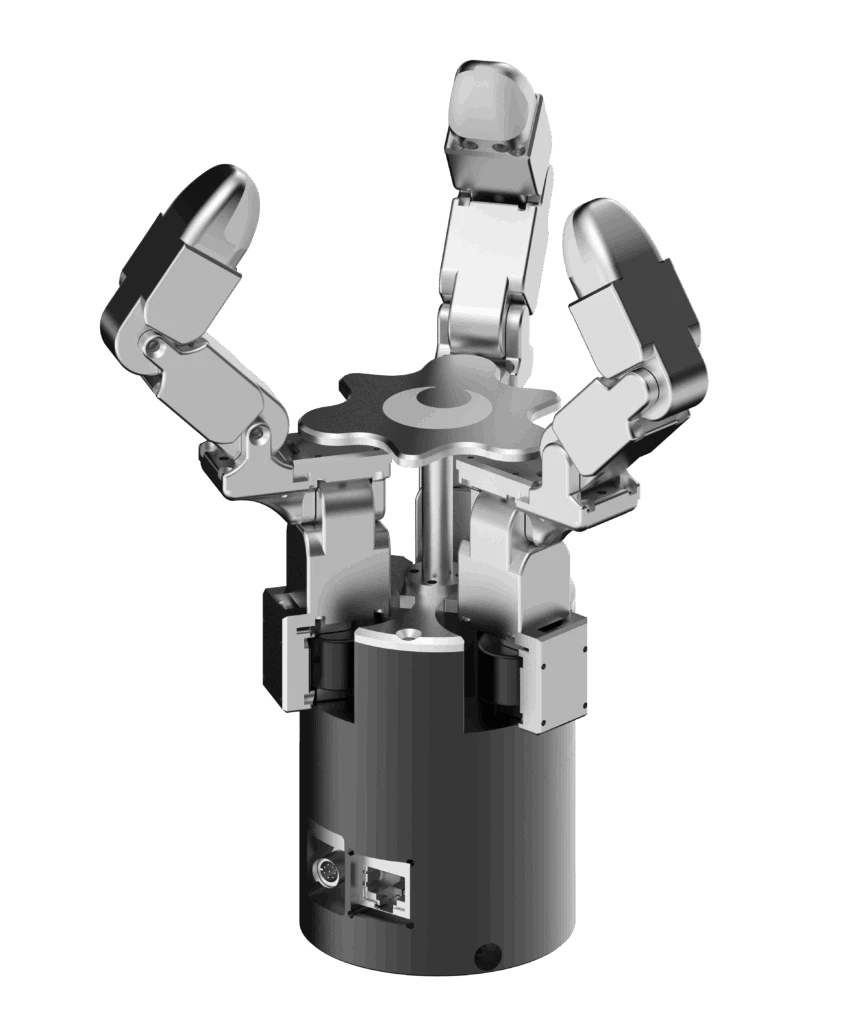
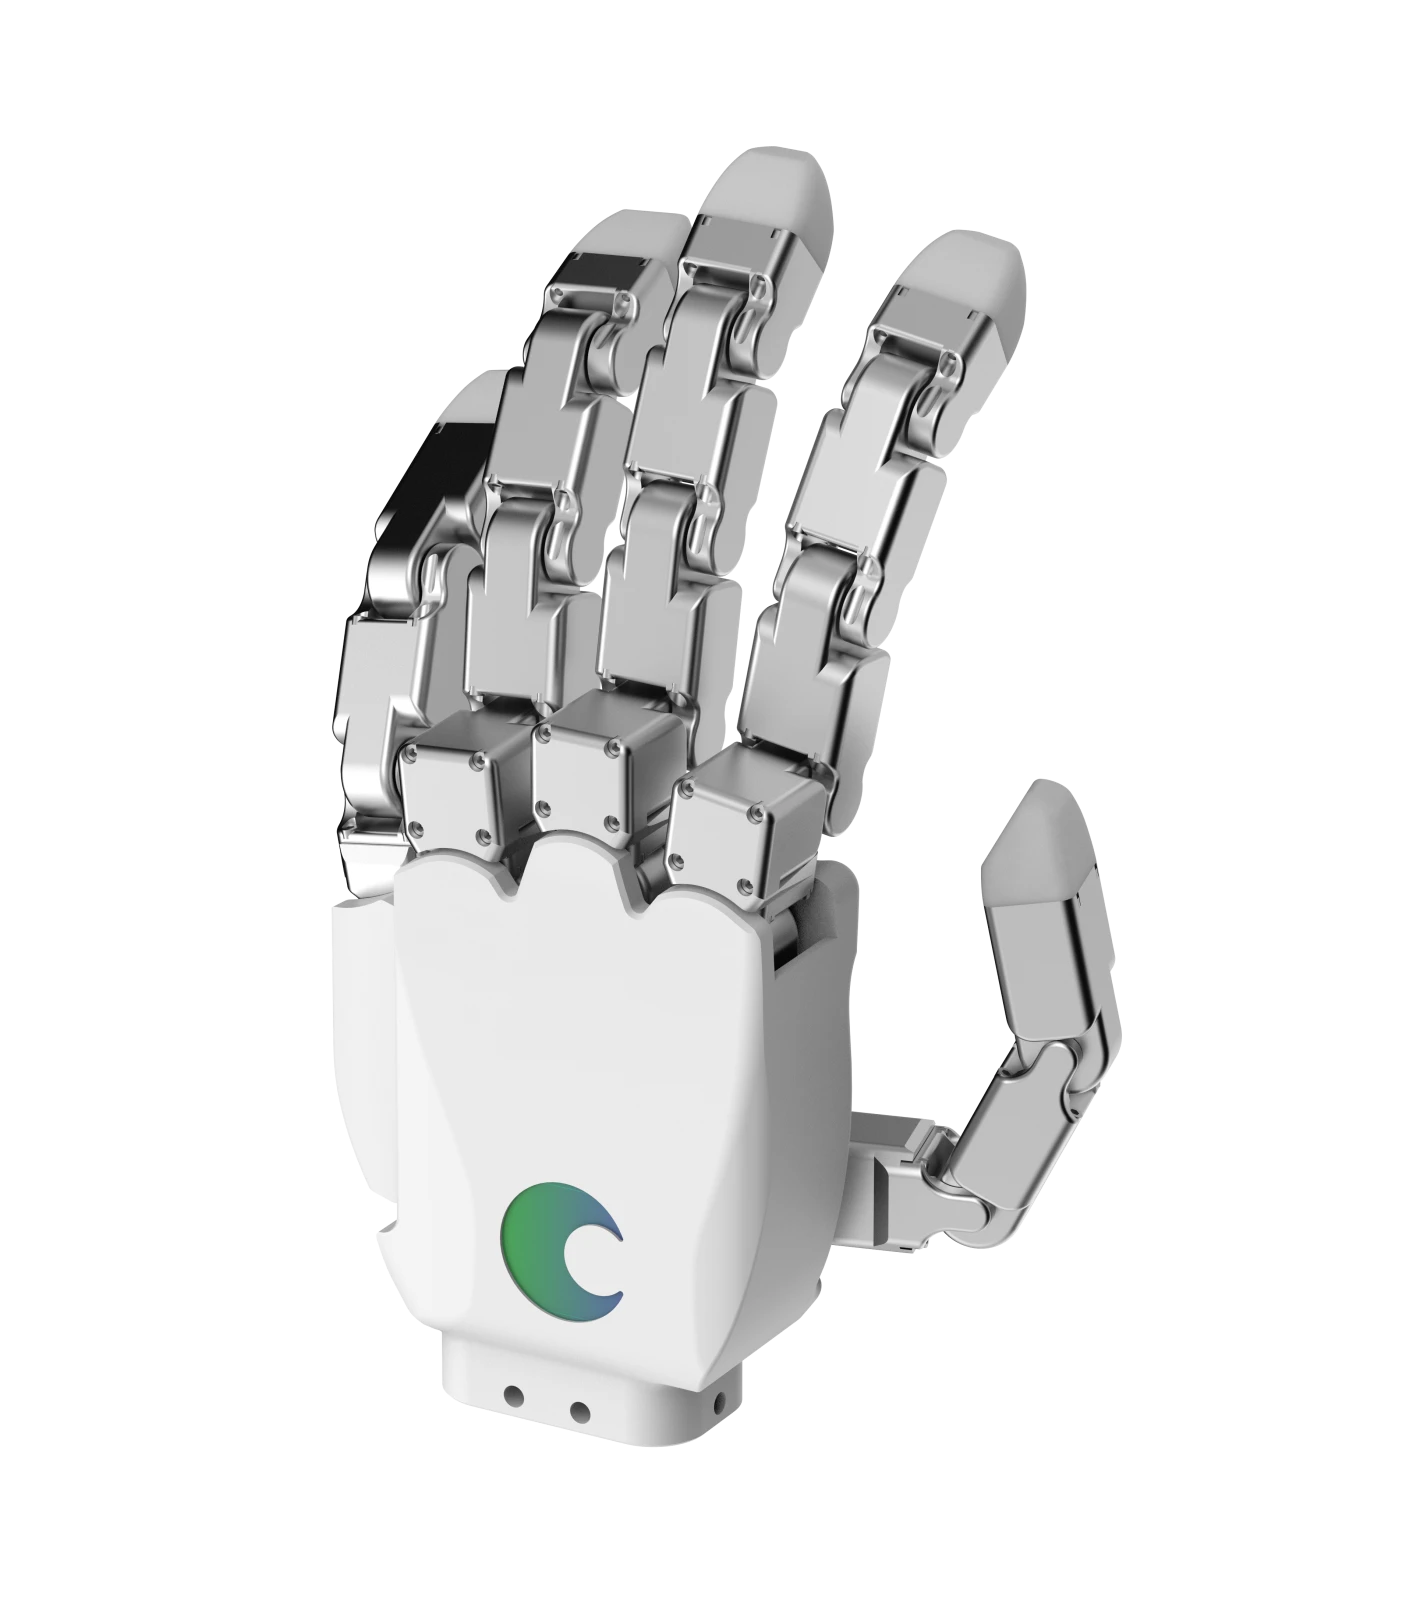
A 20-DoF, adult-hand-sized anthropomorphic robotic hand with a sub-1 kg design, optimized for humanoid platforms and advanced manipulation.

The DG-5F-S is a compact and lightweight high-DoF robotic hand optimized for integration with a wide range of humanoid platforms. With a form factor comparable to an adult human hand and a sub-1 kg design, it minimizes size and weight constraints while maintaining the dexterity required for advanced manipulation.
Its independently controlled joints enable dexterous grasping, in-hand manipulation, tool use, unstructured object handling, and precision assembly and fastening. The DG-5F-S is designed for humanoid research and development, supporting flexible deployment across platform integration, manipulation research, and performance validation.
Independent Joint Control
Each of the 20 joints is driven by its own integrated actuator, enabling fully independent joint control without inter-joint mechanical coupling. This architecture supports precise finger-by-finger motion and coordinated multi-finger manipulation.
Compact and Lightweight Design
With an adult-hand-sized form factor and a sub-1 kg design, the DG-5F-S minimizes size and weight constraints for humanoid integration. Its compact structure enables efficient deployment across a wide range of humanoid robot platforms.
High-Precision Integrated Actuation
Integrated high-precision actuation minimizes backlash and enables accurate positioning with stable joint control for precise manipulation.
Cost-Effective Solution
At approximately 60% of the DG-5F-M price, the DG-5F-S provides a cost-effective solution for research labs, startups, and small-to-mid-sized organizations.
Reliable Grasping and Manipulation
Built-in grasping and manipulation algorithms support stable handling of objects with different shapes and materials, helping improve reliability across a wide range of manipulation tasks.
Customizable Expansion Options
A range of optional configurations and add-on components can be selected according to research goals and platform constraints, supporting flexible setup for humanoid manipulation research and performance validation.