DG-4F
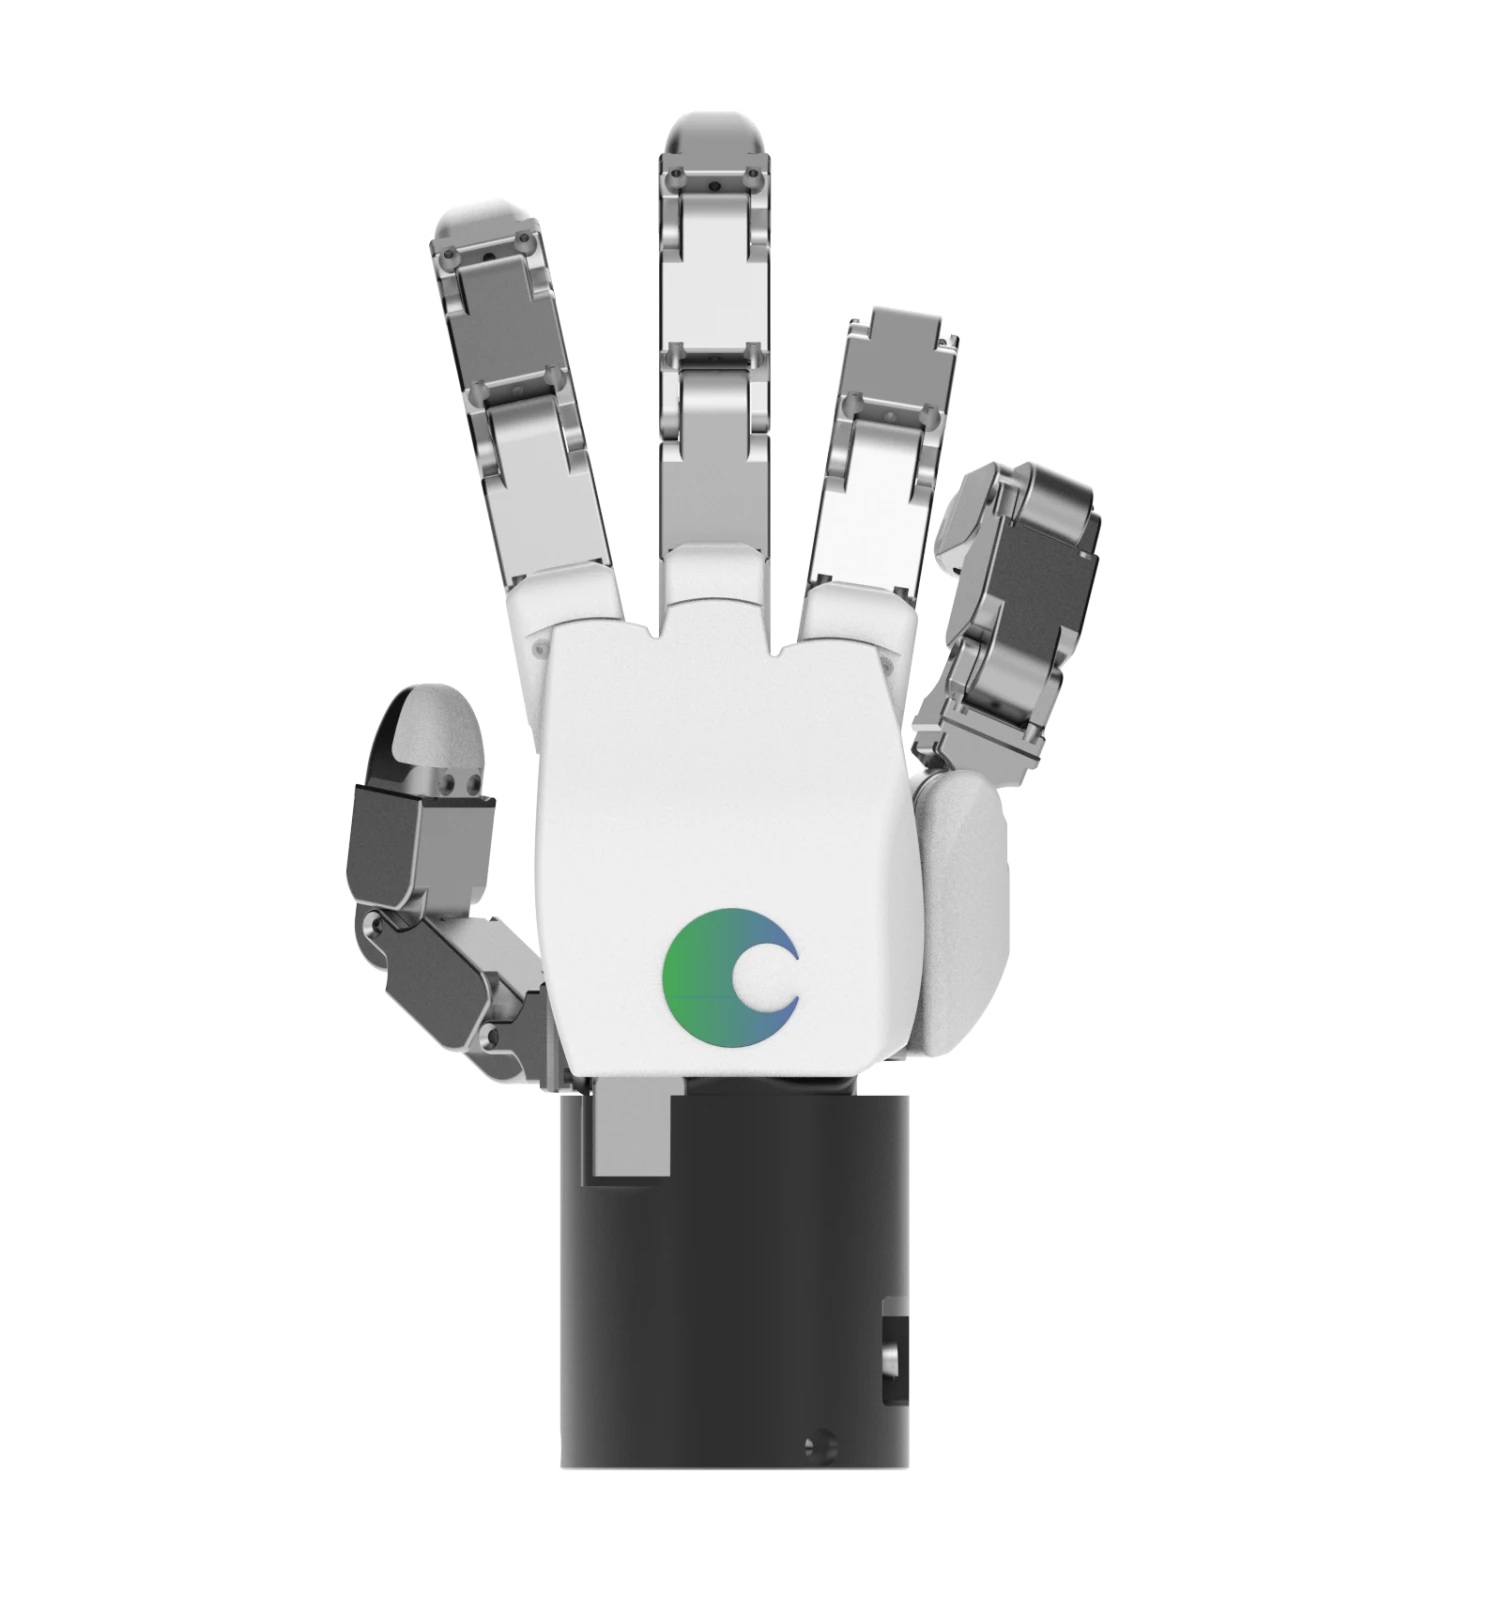
A multi-joint 4-finger robotic gripper with independent finger control, designed for versatile grasping and flexible object manipulation.

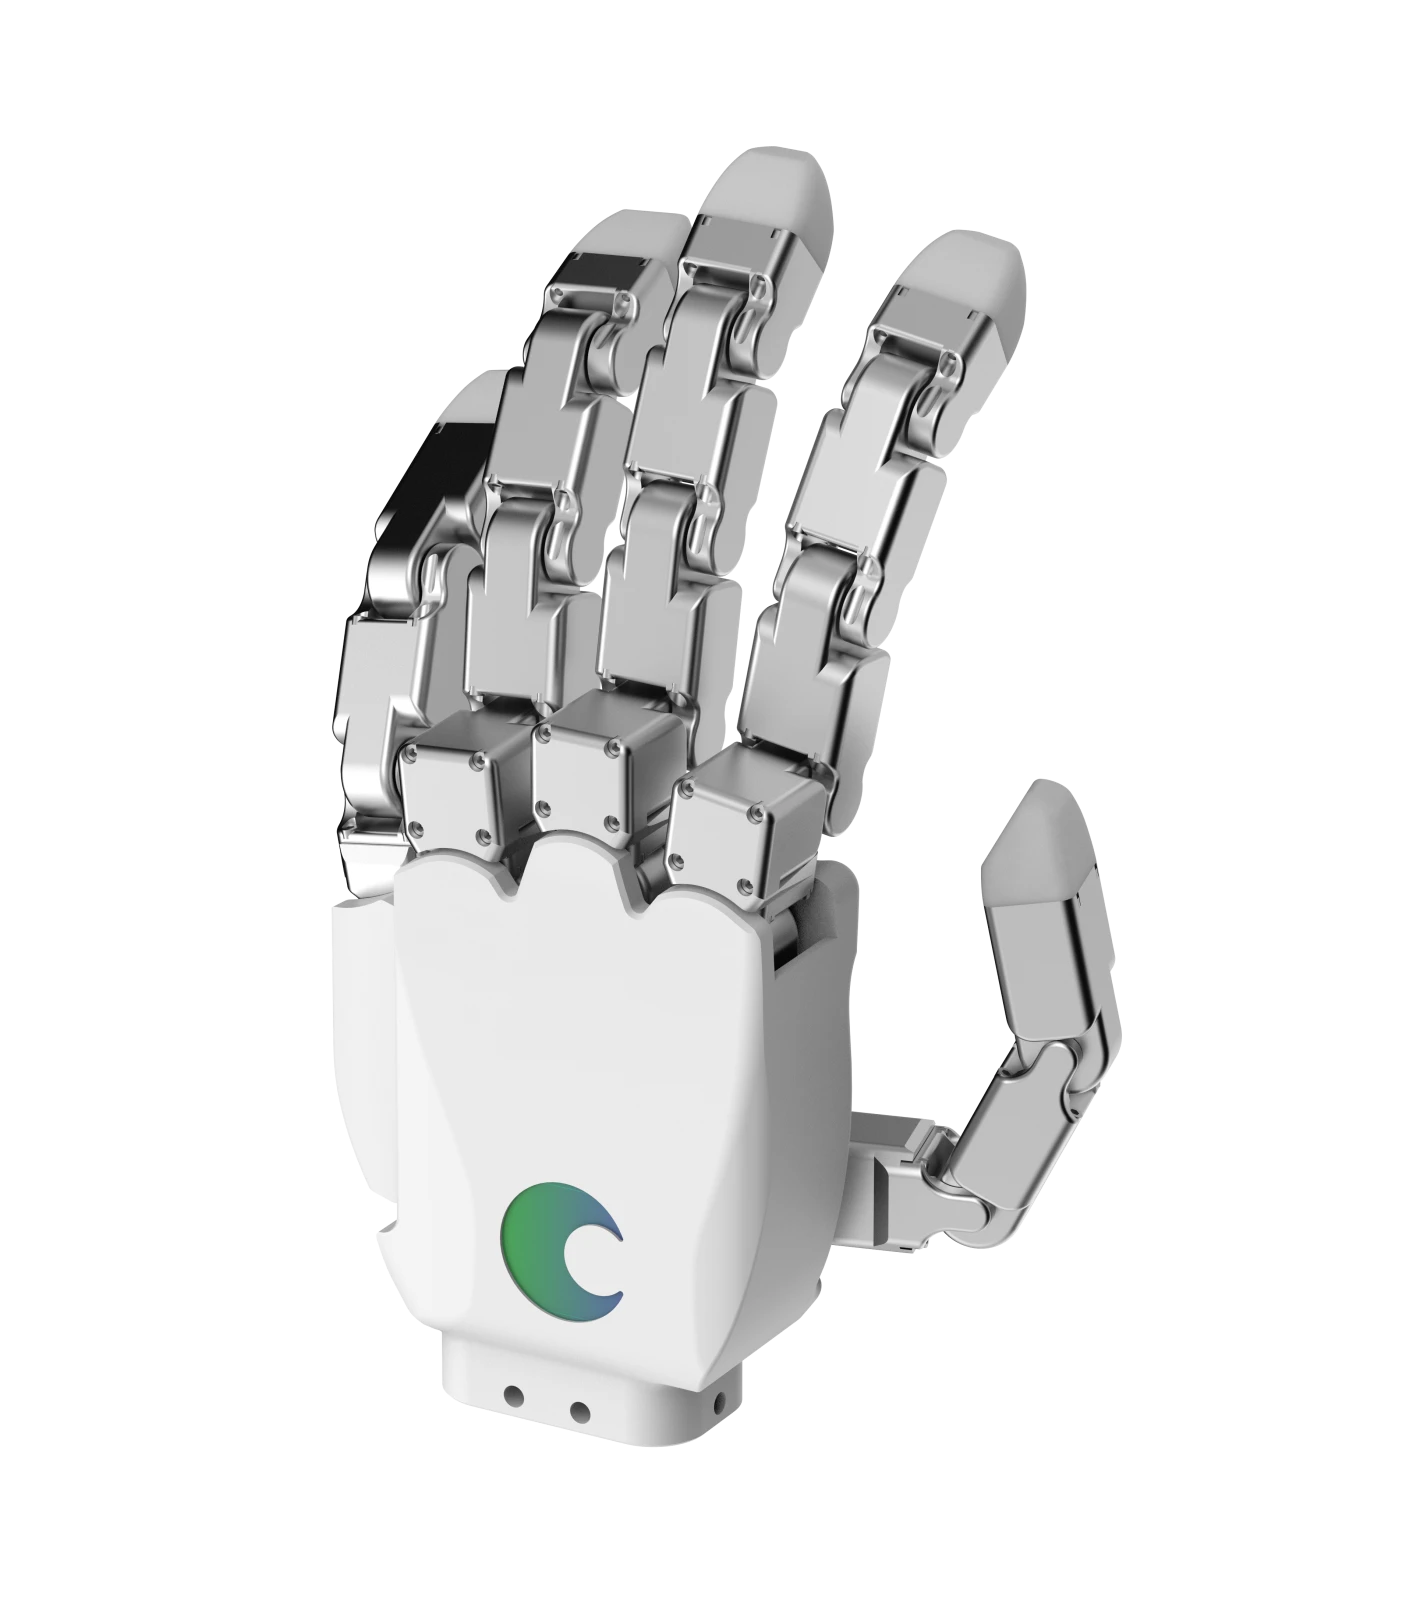
The DG-4F is a versatile 4-finger robotic gripper featuring independently controlled multi-joint fingers for flexible and precise manipulation. Its four-finger architecture supports a wide range of grasping configurations, enabling stable handling of objects with different shapes, sizes, and orientations.
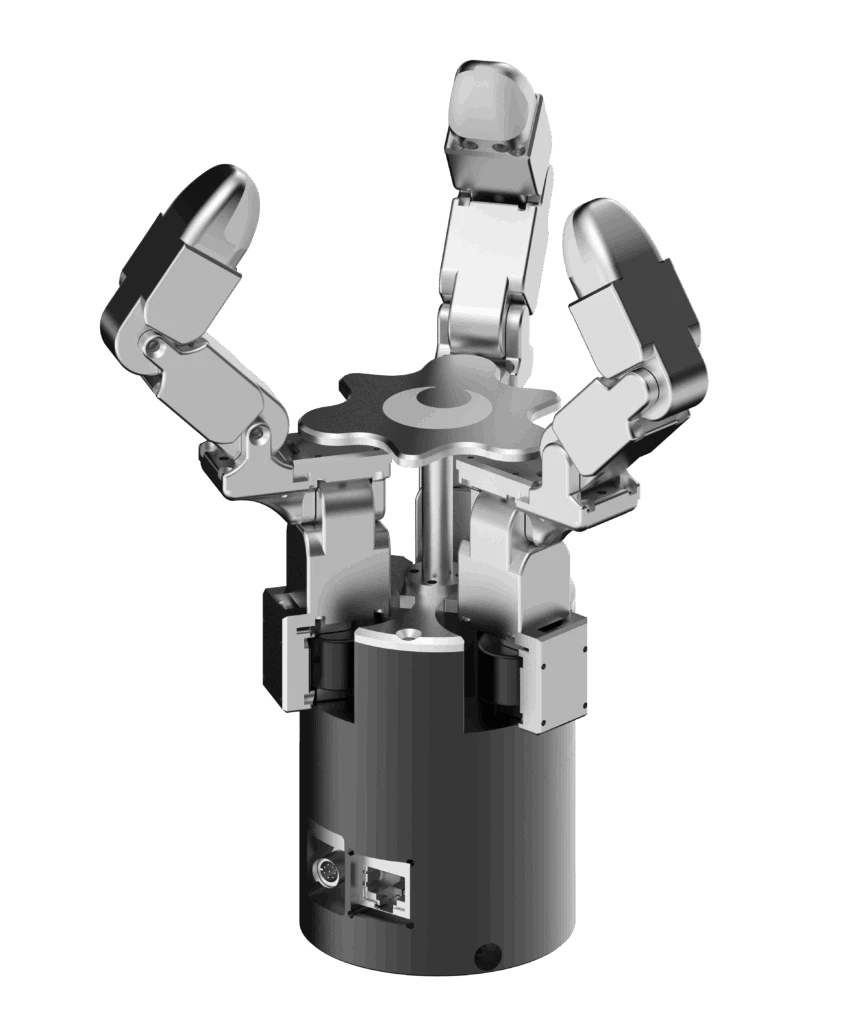
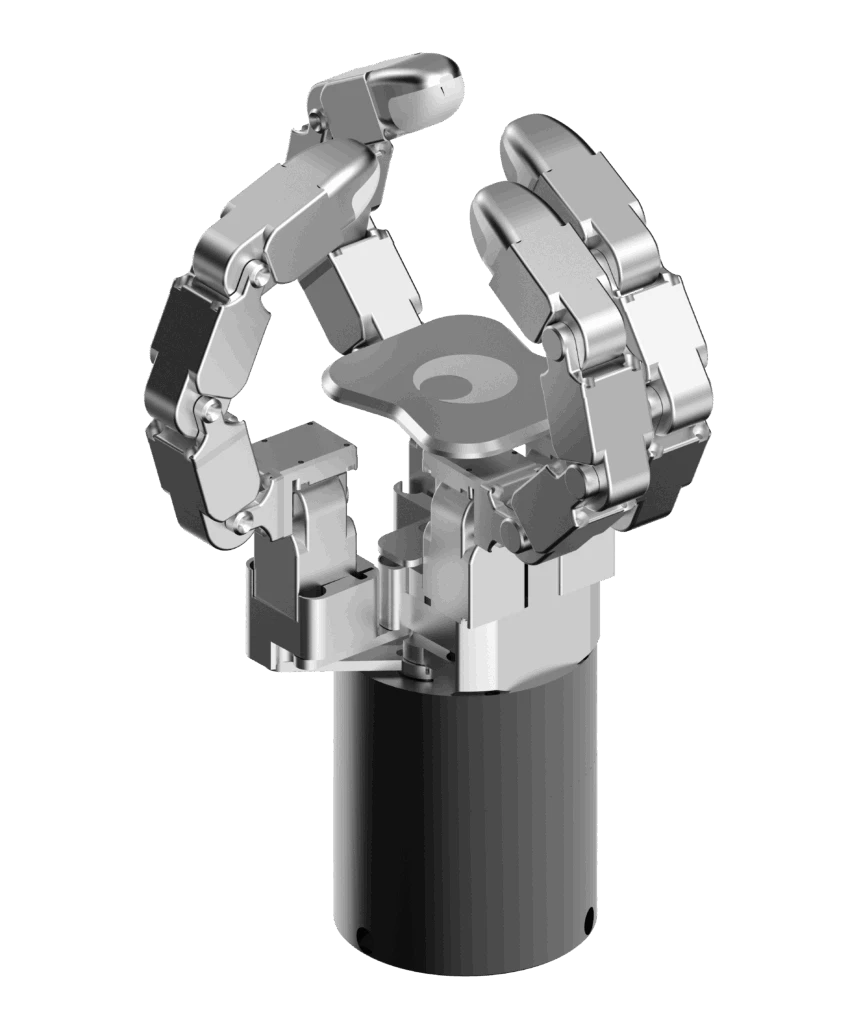
The flexible base-joint structure further expands its range of motion and enables left-hand-like, right-hand-like, and conventional gripper-style configurations. By combining multiple grasping strategies in a single end-effector, the DG-4F is well suited for robotics research, industrial automation, and applications requiring flexible object handling.
Four-Finger Multi-Joint Design
The four independently controlled multi-joint fingers combine hand-like dexterity with the secure grasping capability of a conventional gripper, supporting a broad range of manipulation tasks.
Broad Object Handling Capability
Independent multi-joint finger control enables stable handling of objects across different sizes, shapes, and orientations, including cylindrical, flat, and irregularly shaped objects.
Flexible Base-Joint Configuration
The adjustable base-joint structure expands the gripper’s range of motion and supports left-hand-like, right-hand-like, and conventional gripper-style configurations to suit different task requirements.
Multiple Grip Modes
Supports multiple grasping modes, including Pinch Grip for fingertip grasping, Power Grip for secure full-finger grasping, and Precision Grip using selected fingers for delicate manipulation. The appropriate grip configuration can be selected based on object characteristics and task requirements.
Control and System Integration
Provides a user-friendly control interface and compatibility with a broad range of robotic arms, enabling straightforward integration with existing robotic platforms and control systems.